
VOXL 2 Camera Configurations
Every standard camera config ID for VOXL 2 and VOXL 2 Mini, with the sensor, connector, and pipe name of each camera.
Table of contents
- Overview
- Find your config set
- Camera slots
- Reading the config tables
- Config set 0: VOXL 2 with M0076 / M0135 breakouts
- Config set 1: VOXL 2 with M0173 / M0226 front ends
- Config set 2: VOXL 2 Mini with M0188 / M0195
- Sensors and default streams
- Custom configs
- Config set 0 wiring
- Legacy configurations (Platform Release 0.9.x)
Overview
A camera config tells voxl-camera-server which image sensor is plugged into which camera slot, what each camera’s pipe is called, and which images to rotate. Each standard config has a number. That number is the camera config field of the SKU (the C in MRB-D0005-4-V2-C6), and it is what you pass to voxl-configure-cameras.
This page lists every standard config for VOXL 2 and VOXL 2 Mini. To load one, change one, or write your own, see Configure Cameras.
voxl-configure-cameras 26
Config 0 disables voxl-camera-server. custom loads /data/modalai/custom_camera_config.txt.
Find your config set
The same config number can mean different hardware on different boards, so the configs are split into three sets. voxl-configure-cameras reads the set from the board’s platform setting and only offers configs from that set.
| Config set | Camera hardware | Products |
|---|---|---|
| Set 0 | VOXL 2 with older breakouts and flexes (M0076, M0135, M0084) | Sentinel (D0006), Starling 1 (D0005), D0008 rev 4 and older |
| Set 1 | VOXL 2 with M0173 or M0226 front end, plus J8 adapters | Starling 2, Starling 2 Max, Seeker V5 and newer (D0008 rev 5 and newer, D0019, D0020) |
| Set 2 | VOXL 2 Mini with M0188 or M0195 adapter | Stinger (D0013), T0001 VTX Air Unit |
To see which set your board uses and the configs available on it:
cat /sys/module/voxl_platform_mod/parameters/config
print-camera-configs
The first command prints 0, 1, or 2. print-camera-configs lists the configs your installed voxl-camera-server provides, which can differ from this page on older SDK releases.
Camera slots
voxl-camera-server addresses each camera by slot number (the camera ID). VOXL 2 has three camera groups, J6, J7 and J8, each with an upper and a lower connector.
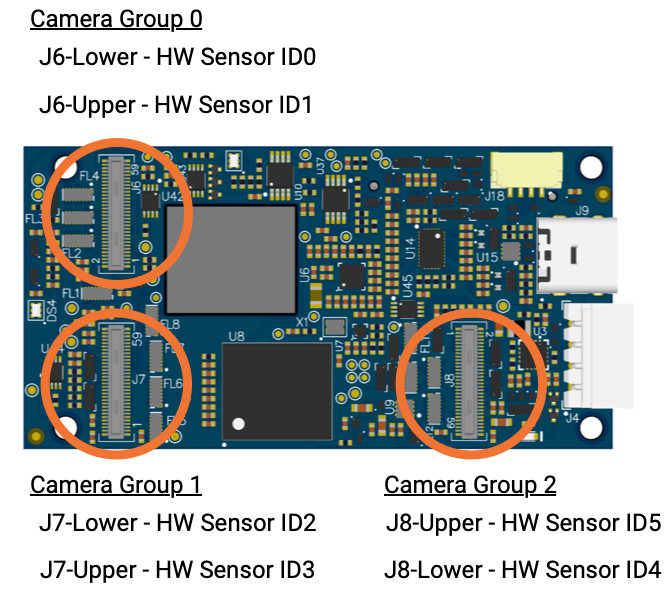
| Slot | VOXL 2 connector | M0173 / M0226 connector | M0188 / M0195 connector (VOXL 2 Mini) |
|---|---|---|---|
| 0 | J6 lower | J1, front tracking | J0, tracking |
| 1 | J6 upper | J4, front hires | J1, hires |
| 2 | J7 lower | J5, down hires | J2, tracking (thermal on M0195) |
| 3 | J7 upper | J3, front ToF | J3, hires |
| 4 | J8 lower | not on the front end, use VOXL 2 J8 | none |
| 5 | J8 upper | not on the front end, use VOXL 2 J8 | none |
| 6 | J6 lower, second camera of a combo pair | J2, down tracking | J6, tracking |
Combo pairs put two cameras on one connector. A combo stereo pair (OV7251 or OV9782) works only on J6 lower (slots 0 and 1) or J8 lower (slots 4 and 5). AR0144 combo pairs use slot 0 for the first camera and slot 6 for the second.
Reading the config tables
- Pipe name is the name the camera’s stream is published under, for example
tracking_frontpublishes/run/mpa/tracking_front. VIO, VOA, and the other services subscribe by these names. - Rotated means the image is flipped 180 degrees, either by the driver or by voxl-camera-server, because the sensor is mounted upside down.
- IMX664 or IMX412 marks a hires slot that ships with either sensor.
voxl-configure-camerasprobes the slot and installs the matching driver: IMX664 answers at address 0x6C and IMX412 at 0x34. If nothing answers it assumes IMX664. “Rotated if IMX412” means only an IMX412 in that slot is flipped. “Rotated if IMX412 on V6” applies when the SKU hardware version is V6, V6A, V6B, and so on. - Configs for the M0173, M0226, M0188 and M0195 boards enable tracking-camera frame sync on GPIO 109.
- With a Nyctis thermal camera the pipe is still named
boson, so the same downstream configuration works with either thermal camera.
Config set 0: VOXL 2 with M0076 / M0135 breakouts
Connectors are on VOXL 2 itself. Wiring photos for most of these configs are under Config set 0 wiring.
| ID | Configuration | Cameras: pipe, sensor, connector (slot) |
|---|---|---|
| 01 | OV7251 stereo and tracking | stereo: OV7251 stereo pair, left-right, J6 lower (slots 0, 1)tracking: OV7251, J7 lower (slot 2) |
| 02 | OV7251 tracking only | tracking: OV7251, J7 lower (slot 2) |
| 03 | OV7251 stereo, tracking, and IMX214 hires | stereo: OV7251 stereo pair, left-right, J6 lower (slots 0, 1)tracking: OV7251, J7 lower (slot 2)hires: IMX214, J7 upper (slot 3) |
| 04 | OV7251 tracking and IMX214 hires | tracking: OV7251, J7 lower (slot 2)hires: IMX214, J7 upper (slot 3) |
| 05 | ToF and OV7251 tracking | tof: PMD ToF, J6 lower (slot 0)tracking: OV7251, J7 lower (slot 2) |
| 06 | D0005 Starling: ToF, IMX214 hires, and OV7251 tracking | tof: PMD ToF, J6 lower (slot 0)hires: IMX214, J7 lower (slot 2)tracking: OV7251, J7 upper (slot 3) |
| 08 | IMX214 hires only | hires: IMX214, J7 upper (slot 3) |
| 09 | ToF only | tof: PMD ToF, J6 lower (slot 0) |
| 10 | OV7251 stereo only | stereo: OV7251 stereo pair, left-right, J6 lower (slots 0, 1) |
| 11 | D0006 Sentinel: front and rear OV7251 stereo, tracking, and IMX214 hires | stereo_front: OV7251 stereo pair, left-right, J6 lower (slots 0, 1), rotatedtracking: OV7251, J7 lower (slot 2)hires: IMX214, J7 upper (slot 3)stereo_rear: OV7251 stereo pair, right-left, J8 lower (slots 4, 5) |
| 12 | OV9782 pair as two independent cameras | trackingL, trackingR: OV9782 pair, J6 lower (slots 0, 1) |
| 13 | OV9782 stereo and IMX214 hires | stereo: OV9782 stereo pair, left-right, J6 lower (slots 0, 1)hires: IMX214, J7 upper (slot 3) |
| 14 | ToF, IMX214 hires, and OV7251 tracking (same cameras as 06) | tof: PMD ToF, J6 lower (slot 0)hires: IMX214, J7 lower (slot 2)tracking: OV7251, J7 upper (slot 3) |
| 15 | D0008 rev 4 and older: OV9782 stereo | stereo: OV9782 stereo pair, left-right, J6 lower (slots 0, 1) |
| 16 | ToF, IMX214 hires, and two OV7251 tracking | tof: PMD ToF, J6 lower (slot 0)hires: IMX214, J7 lower (slot 2)tracking: OV7251, J7 upper (slot 3)tracking2: OV7251, J8 lower (slot 4) |
| 17 | D0010: ToF, IMX412 hires, OV7251 tracking, and OV9782 stereo | tof: PMD ToF, J6 lower (slot 0)hires: IMX412, J7 lower (slot 2)tracking: OV7251, J7 upper (slot 3)stereo: OV9782 stereo pair, left-right, J8 lower (slots 4, 5) |
| 18 | D0008 rev 4 and older: three OV9782 | trackingL, trackingR: OV9782 pair, J6 lower (slots 0, 1)hires: OV9782, J8 lower (slot 4) |
| 19 | D0005 Starling without ToF: IMX214 hires and OV7251 tracking | hires: IMX214, J7 lower (slot 2)tracking: OV7251, J7 upper (slot 3) |
| 20 | D0011: IMX412 hires and AR0144 tracking | hires: IMX412, J7 lower (slot 2), rotatedtracking: AR0144, J7 upper (slot 3) |
| 21 | ToF, OV7251 tracking, and IMX214 hires (old C6 layout) | tof: PMD ToF, J6 lower (slot 0)tracking: OV7251, J7 lower (slot 2)hires: IMX214, J7 upper (slot 3) |
| 23 | D0010 without stereo: ToF, IMX412 hires, and OV7251 tracking | tof: PMD ToF, J6 lower (slot 0)hires: IMX412, J7 lower (slot 2)tracking: OV7251, J7 upper (slot 3) |
| 24 | ToF only, IRS2975C (LIOW2) sensor | tof: PMD ToF (LIOW2), J6 lower (slot 0) |
| 31 | D0013 Stinger prototype on M0135: two AR0144 tracking | tracking_down: AR0144, J6 lower (slot 0)tracking_front: AR0144, J7 lower (slot 2), rotated |
| 32 | D0008 rev 4 and older: three OV9782, hires rotated | trackingL, trackingR: OV9782 pair, J6 lower (slots 0, 1)hires: OV9782, J8 lower (slot 4), rotated |
Config set 1: VOXL 2 with M0173 / M0226 front ends
Connectors J1 to J5 are on the M0173 or M0226 front end. J8 cameras plug into VOXL 2 J8 through an adapter such as M0076 or M0135, or the M0181 adapter on Seeker V6.
| ID | Configuration | Cameras: pipe, sensor, connector (slot) |
|---|---|---|
| 22 | Seeker V5: dual AR0144 tracking | tracking_front: AR0144, J1 (slot 0)tracking_down: AR0144, J2 (slot 6), rotated |
| 26 | Starling 2: IMX412 hires, ToF, and dual AR0144 tracking | tracking_front: AR0144, J1 (slot 0), rotatedhires: IMX412, J4 (slot 1)tof: PMD ToF (LIOW2), J3 (slot 3)tracking_down: AR0144, J2 (slot 6) |
| 27 | Starling 2: IMX412 hires, ToF, and three AR0144 tracking | tracking_front: AR0144, J1 (slot 0), rotatedhires: IMX412, J4 (slot 1)tracking_rear: AR0144, J5 (slot 2), rotatedtof: PMD ToF (LIOW2), J3 (slot 3)tracking_down: AR0144, J2 (slot 6) |
| 28 | Starling 2 Max: two IMX412 hires and dual AR0144 tracking | tracking_front: AR0144, J1 (slot 0), rotatedhires_front: IMX412, J4 (slot 1)hires_down: IMX412, J5 (slot 2)tracking_down: AR0144, J2 (slot 6) |
| 29 | Starling 2 Max: two IMX412 hires, ToF, and dual AR0144 tracking | tracking_front: AR0144, J1 (slot 0), rotatedhires_front: IMX412, J4 (slot 1)hires_down: IMX412, J5 (slot 2)tof: PMD ToF (LIOW2), J3 (slot 3)tracking_down: AR0144, J2 (slot 6) |
| 30 | Starling 2 prototype: two IMX412 hires, two ToF, and dual AR0144 tracking | tracking_front: AR0144, J1 (slot 0), rotatedhires_front: IMX412, J4 (slot 1)hires_down: IMX412, J5 (slot 2)tof: PMD ToF (LIOW2), J3 (slot 3)tof2: PMD ToF (LIOW2), VOXL 2 J8 lower (slot 4)tracking_down: AR0144, J2 (slot 6) |
| 36 | Seeker V5: IMX412 hires and dual AR0144 tracking | tracking_front: AR0144, J1 (slot 0)hires: IMX412, J4 (slot 1)tracking_down: AR0144, J2 (slot 6), rotated |
| 37 | Seeker V5: IMX412 hires, dual AR0144 tracking, and Boson | tracking_front: AR0144, J1 (slot 0)hires: IMX412, J4 (slot 1)boson: Boson, VOXL 2 J8 lower (slot 4)tracking_down: AR0144, J2 (slot 6), rotated |
| 46 | Seeker V5: IMX664 or IMX412 hires and dual AR0144 tracking | tracking_front: AR0144, J1 (slot 0)hires: IMX664 or IMX412, J5 (slot 2), rotated if IMX412 on V6tracking_down: AR0144, J2 (slot 6), rotated |
| 47 | Seeker V5: IMX664 or IMX412 hires, dual AR0144 tracking, and Boson | tracking_front: AR0144, J1 (slot 0)hires: IMX664 or IMX412, J5 (slot 2), rotated if IMX412 on V6boson: Boson, VOXL 2 J8 lower (slot 4)tracking_down: AR0144, J2 (slot 6), rotated |
| 48 | Seeker V5: IMX664 or IMX412 hires, dual AR0144 tracking, and Nyctis | tracking_front: AR0144, J1 (slot 0)hires: IMX664 or IMX412, J5 (slot 2), rotated if IMX412 on V6boson: Nyctis 640, VOXL 2 J8 lower (slot 4)tracking_down: AR0144, J2 (slot 6), rotated |
| 50 | Seeker V5: IMX664 or IMX412 hires only | hires: IMX664 or IMX412, J5 (slot 2), rotated if IMX412 on V6 |
| 51 | Seeker V5: IMX664 or IMX412 hires and Boson | hires: IMX664 or IMX412, J5 (slot 2), rotated if IMX412 on V6boson: Boson, VOXL 2 J8 lower (slot 4) |
| 60 | Seeker V6 on M0181: IMX664 or IMX412 hires only | hires: IMX664 or IMX412, VOXL 2 J8 upper (slot 5), rotated if IMX412 |
| 61 | Seeker V6 on M0226: IMX664 or IMX412 hires and AR0144 stereo | tracking_left: AR0144, J1 (slot 0), rotatedhires: IMX664 or IMX412, J5 (slot 2), rotated if IMX412tracking_right: AR0144, J2 (slot 6), rotated |
| 62 | Seeker V6 on M0226: IMX664 or IMX412 hires, AR0144 stereo, and Boson | tracking_left: AR0144, J1 (slot 0), rotatedhires: IMX664 or IMX412, J5 (slot 2), rotated if IMX412boson: Boson, VOXL 2 J8 lower (slot 4)tracking_right: AR0144, J2 (slot 6), rotated |
| 63 | Seeker V6 on M0226: IMX664 or IMX412 hires, AR0144 stereo, and Nyctis | tracking_left: AR0144, J1 (slot 0), rotatedhires: IMX664 or IMX412, J5 (slot 2), rotated if IMX412boson: Nyctis 640, VOXL 2 J8 lower (slot 4)tracking_right: AR0144, J2 (slot 6), rotated |
| 64 | Seeker V6 on M0226: IMX664 or IMX412 hires, AR0144 stereo, down AR0144, and Boson | tracking_left: AR0144, J1 (slot 0), rotatedtracking_down: AR0144, J4 (slot 1)hires: IMX664 or IMX412, J5 (slot 2), rotated if IMX412boson: Boson, VOXL 2 J8 lower (slot 4)tracking_right: AR0144, J2 (slot 6), rotated |
Config set 2: VOXL 2 Mini with M0188 / M0195
Connectors are on the M0188 or M0195 adapter. M0195 adds a thermal camera port on J2.
| ID | Configuration | Cameras: pipe, sensor, connector (slot) |
|---|---|---|
| 22 | D0013 Stinger on M0188: dual AR0144 tracking | tracking_front: AR0144, J0 (slot 0), rotatedtracking_down: AR0144, J6 (slot 6), encoded stream rotated 90 degrees |
| 33 | D0013 Stinger on M0188: IMX664 or IMX412 hires and dual AR0144 tracking | tracking_front: AR0144, J0 (slot 0), rotatedhires: IMX664 or IMX412, J1 (slot 1)tracking_down: AR0144, J6 (slot 6), encoded stream rotated 90 degrees |
| 34 | D0013 Stinger on M0195: IMX664 or IMX412 hires (rotated), dual AR0144 tracking, and Boson | tracking_front: AR0144, J0 (slot 0), rotatedhires: IMX664 or IMX412, J1 (slot 1), rotatedboson: Boson, J2 (slot 2)tracking_down: AR0144, J6 (slot 6), encoded stream rotated 90 degrees |
| 35 | D0013 Stinger on M0195: IMX664 or IMX412 hires (rotated) and dual AR0144 tracking | tracking_front: AR0144, J0 (slot 0), rotatedhires: IMX664 or IMX412, J1 (slot 1), rotatedtracking_down: AR0144, J6 (slot 6), encoded stream rotated 90 degrees |
| 50 | T0001 VTX Air Unit: IMX664 hires | hires: IMX664, slot 3 |
| 51 | T0001 VTX Air Unit: IMX664 hires and Boson | boson: Boson, slot 2hires: IMX664, slot 3 |
| 52 | T0001 VTX Air Unit: two IMX664 hires and Boson | hires2: IMX664, slot 0boson: Boson, slot 2hires1: IMX664, slot 3 |
Sensors and default streams
The sensor keywords below are the values used in config files and in a custom config. When a config is loaded, voxl-camera-server writes these defaults to /etc/modalai/voxl-camera-server.conf; change resolution and frame rate there.
| Keyword | Sensor | Modules | Default stream |
|---|---|---|---|
ov7251, ov7251-combo | OV7251, global shutter, mono | M0014, M0015 | 640x480, 30 fps |
ov9782, ov9782-combo, ov9782-combo2 | OV9782, global shutter, color | M0113 | 1280x800, 30 fps |
ar0144, ar0144-fsin, ar0144-fsin-combo, ar0144-fsin-combo-rotated | AR0144, global shutter, mono | M0149, M0166 | 1280x800, 30 fps |
ar0144-12bit, ar0144-12bit-fsin, ar0144-12bit-fsin-combo | AR0144, 12-bit output | M0149, M0166 | 1280x800, 30 fps |
imx214 | IMX214, 13 MP | M0025 | 640x480 preview, 4208x3120 video and snapshot, 30 fps |
imx412, imx412-fpv | IMX412, 12 MP | M0107, M0161 | 640x480 preview, 4056x3040 video and snapshot, 30 fps |
imx412-fpv-v2 | IMX412, FPV driver | M0161 | 1936x1080 at 60 fps, 1280x720 MISP stream |
imx664, imx664-fpv | IMX664 | M0186 | 2704x1540 at 60 fps, 1280x720 MISP stream, ClearHDR on for imx664-fpv |
imx664-or-imx412 | IMX664 or IMX412, detected at configure time | as imx664-fpv or imx412-fpv-v2 | |
imx678 | IMX678 | M0061 | 640x480 preview, 2048x1536 video, 30 fps |
pmd-tof | PMD ToF, IRS1645 | M0040 | 5 fps |
pmd-tof-liow2 | PMD ToF, IRS2975C | M0169, M0178 | 10 fps |
boson, boson-fpv | FLIR Boson 640, thermal | M0153 adapter | 640x512, 30 fps |
nyctis640 | Nyctis 640, thermal | 640x480, 30 fps |
-combo sensors are one camera of a pair on a combo flex. -fsin sensors take an external frame sync input. ar0144-fsin-combo-rotated rotates only the encoded stream, by 90 degrees (misp_venc_rotation in the camera server config); the raw stream is unchanged.
Custom configs
When no standard config matches your hardware, copy the template to /data/modalai/, edit it, and load it:
cp /usr/share/modalai/voxl-camera-server/custom_camera_config.txt /data/modalai/
voxl-configure-cameras custom
The template documents every field (<PORT>_SENSOR, _NAME, _ROTATE, _COMBO_MODE, _NAME2). The standard configs in /usr/share/modalai/voxl-camera-server/standard_configs/ are good starting points. Only the standard configs are supported. See Configure Cameras for the full procedure.
Config set 0 wiring
The photos show VOXL 2 with set 0 configs connected. Sensor types are listed in the set 0 table.
Config 01: OV7251 stereo and tracking

Config 02: OV7251 tracking only

Config 03: OV7251 stereo, tracking, and IMX214 hires

Config 04: OV7251 tracking and IMX214 hires

Config 05: ToF and OV7251 tracking

Config 06: D0005 Starling: ToF, IMX214 hires, and OV7251 tracking
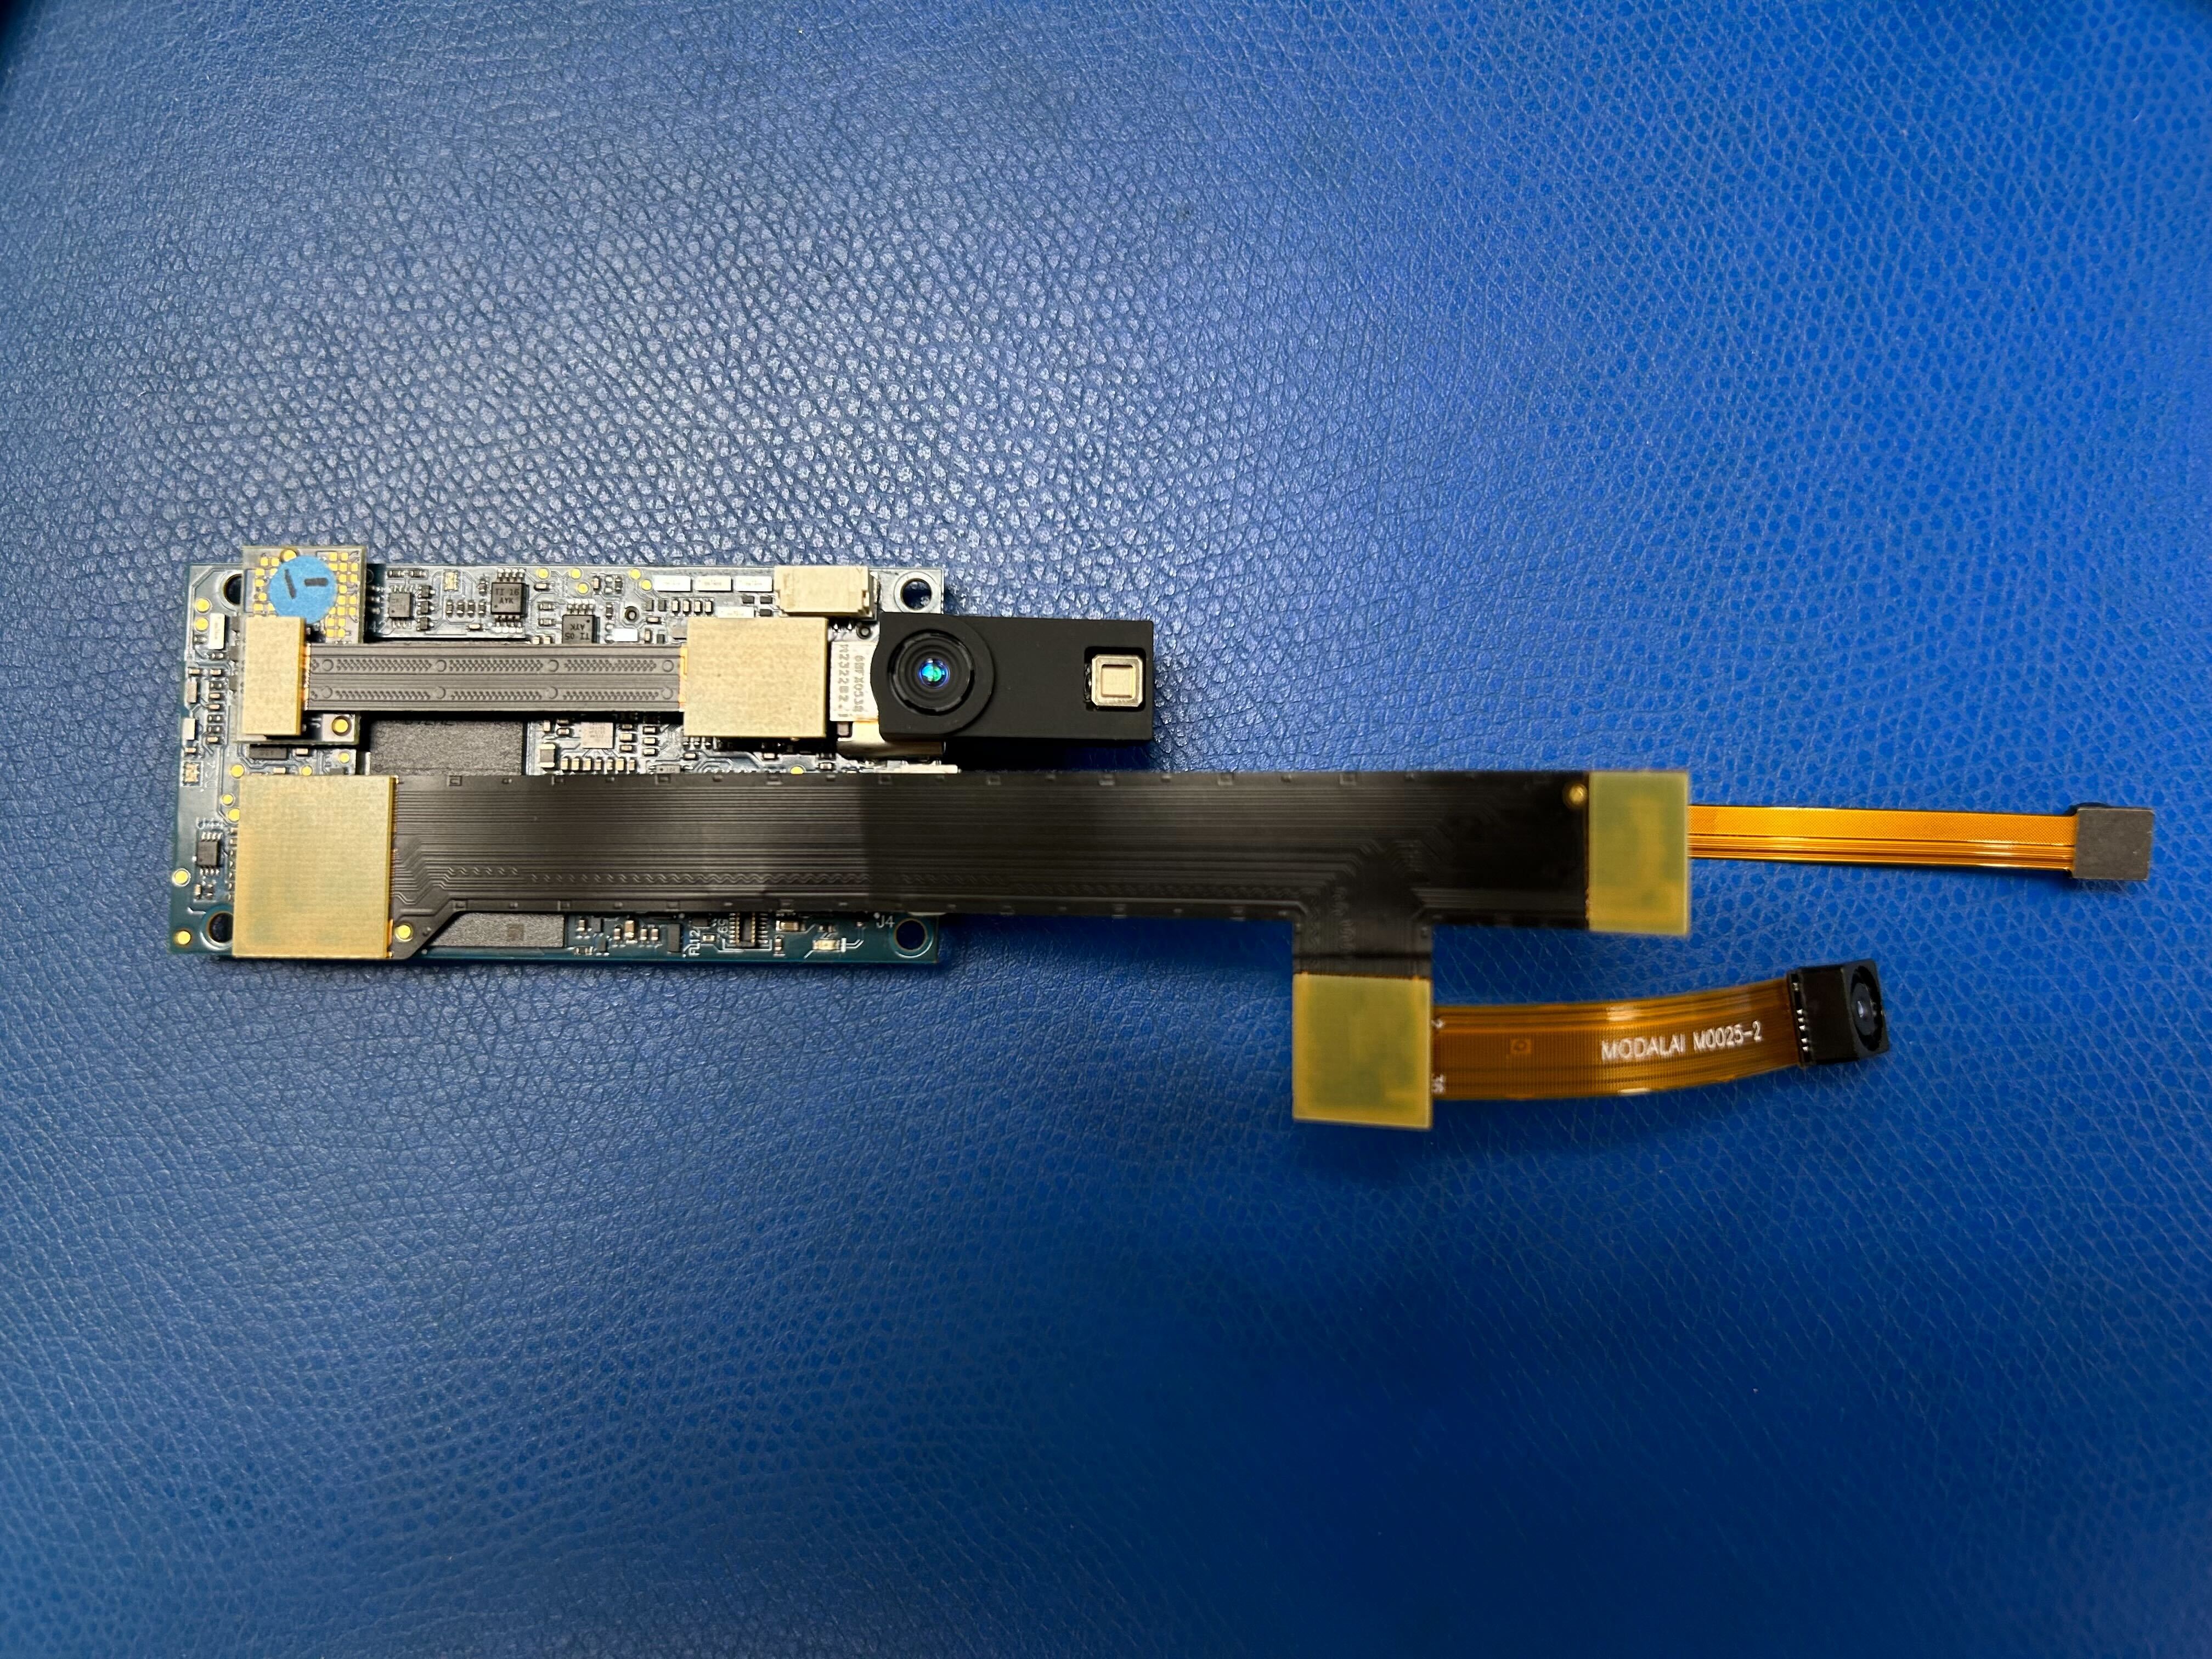
Config 14 uses the same wiring.
Config 08: IMX214 hires only
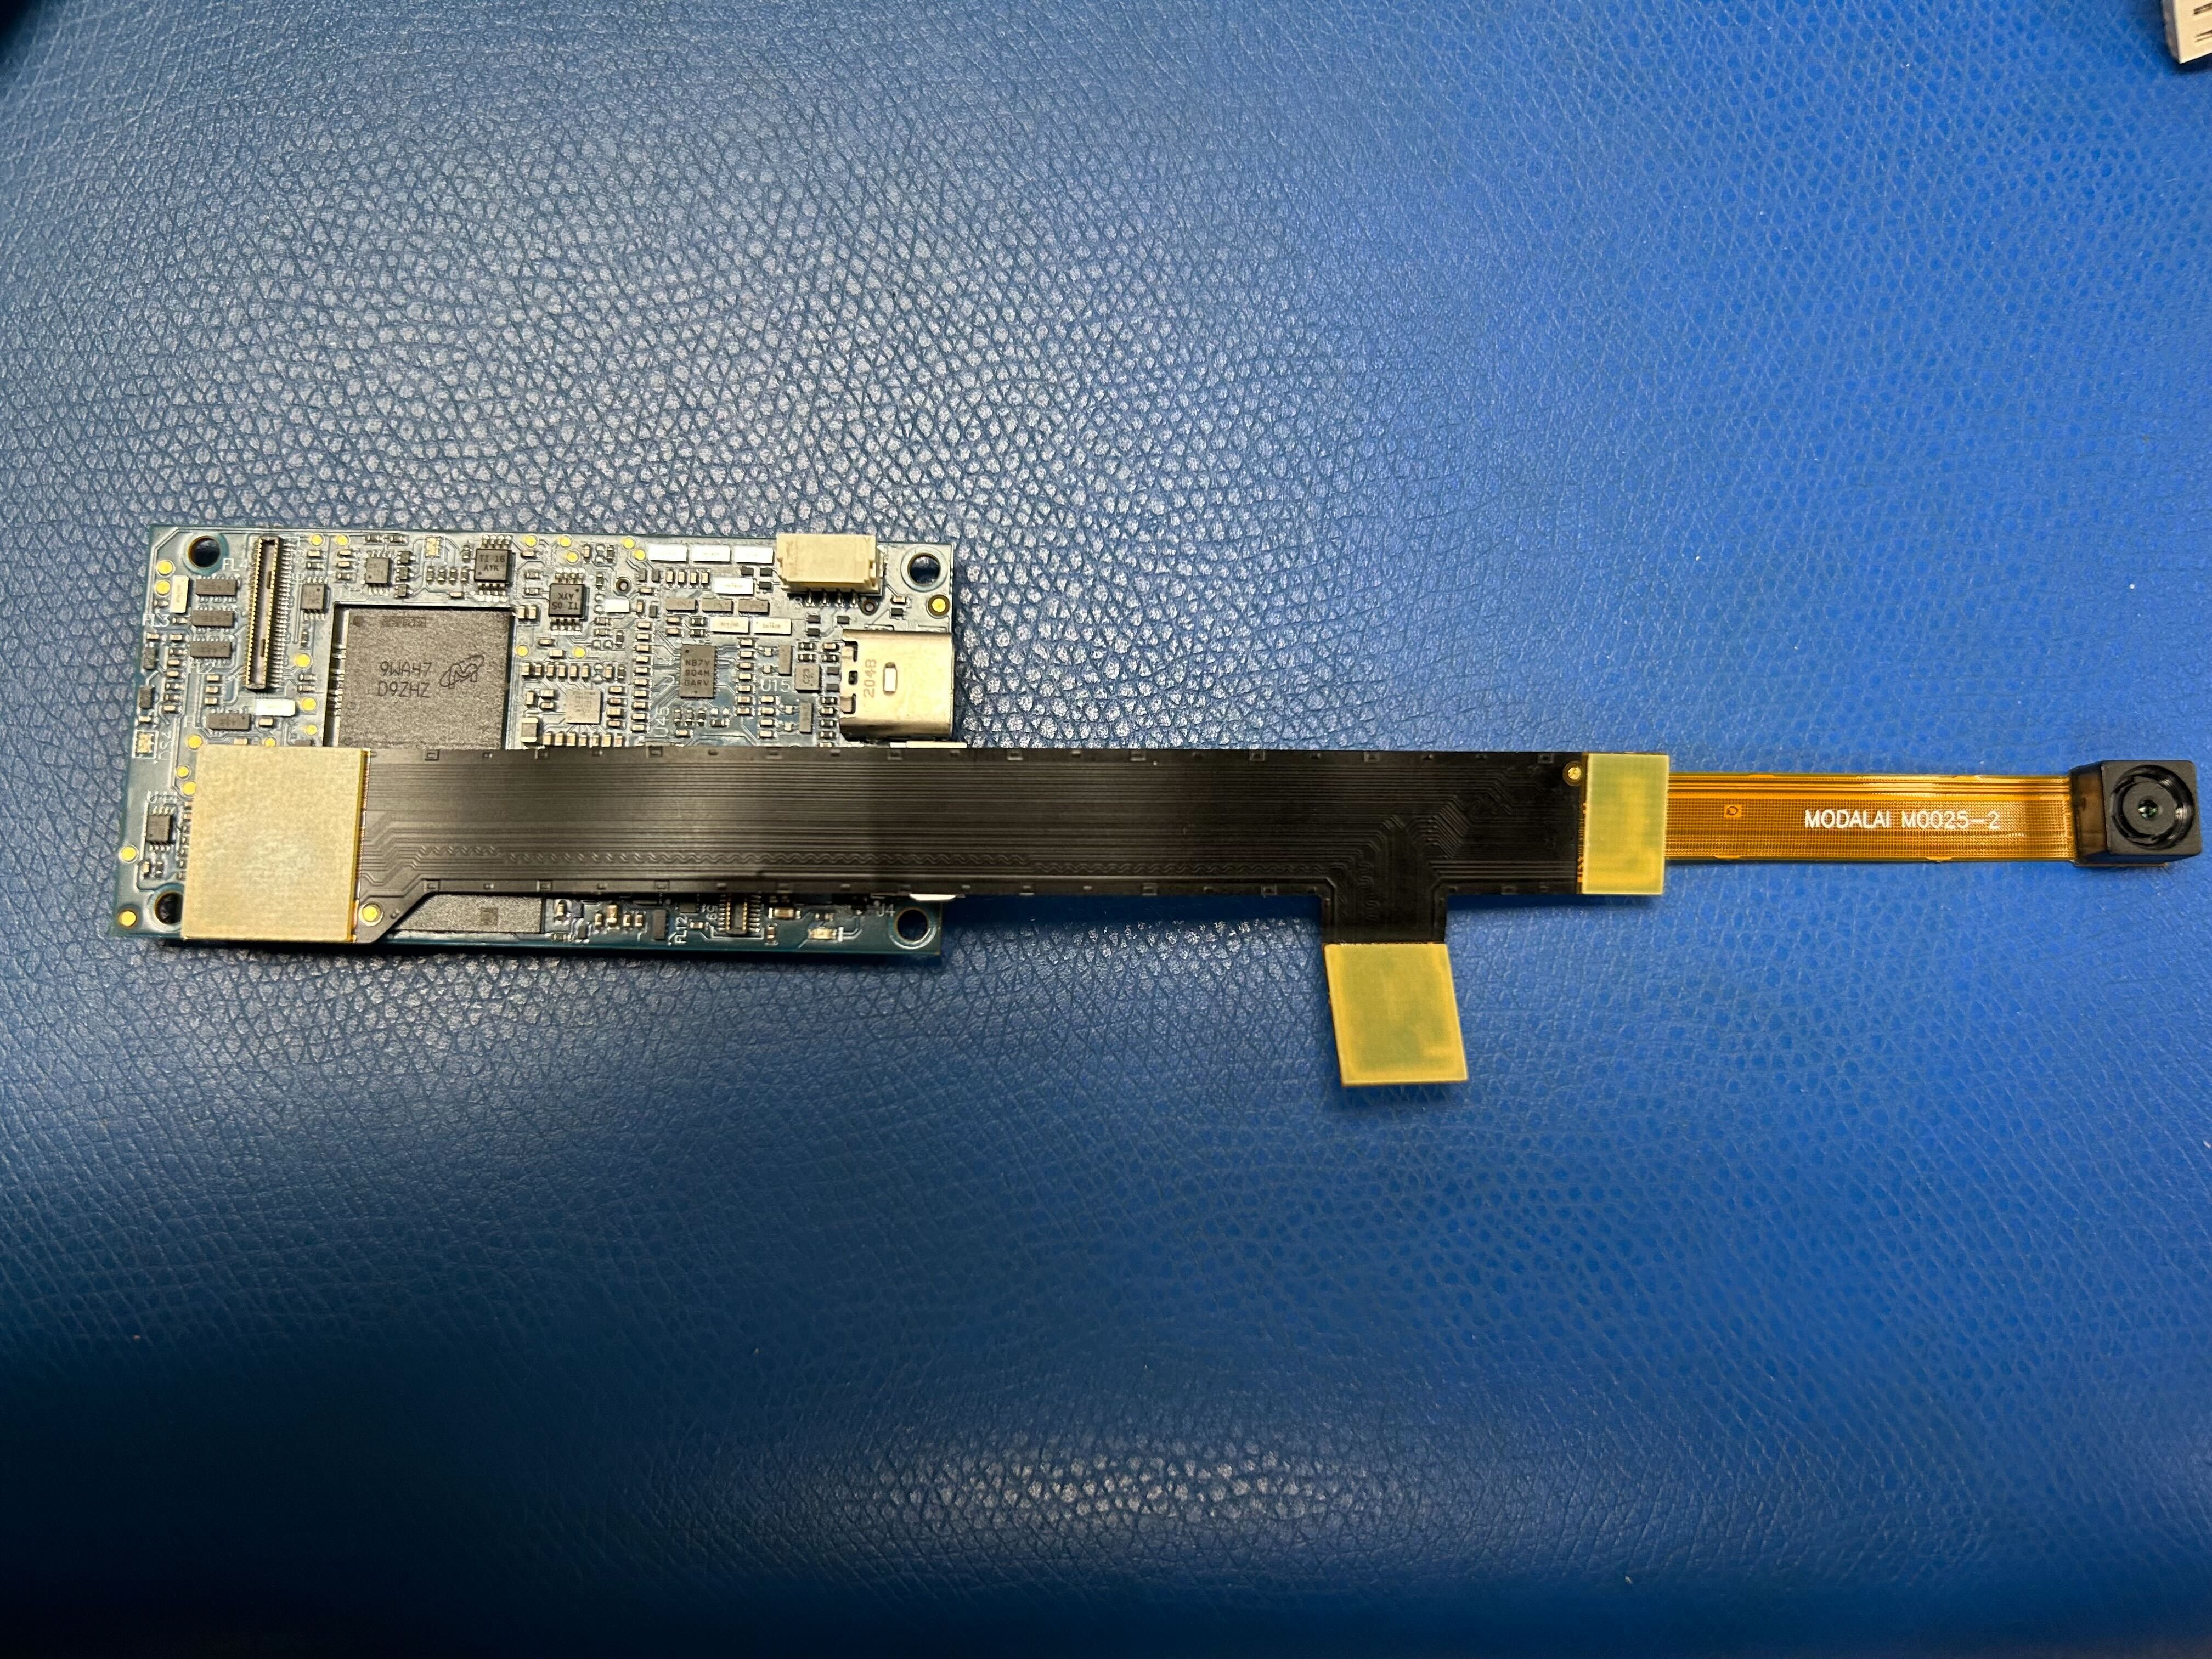
Config 09: ToF only
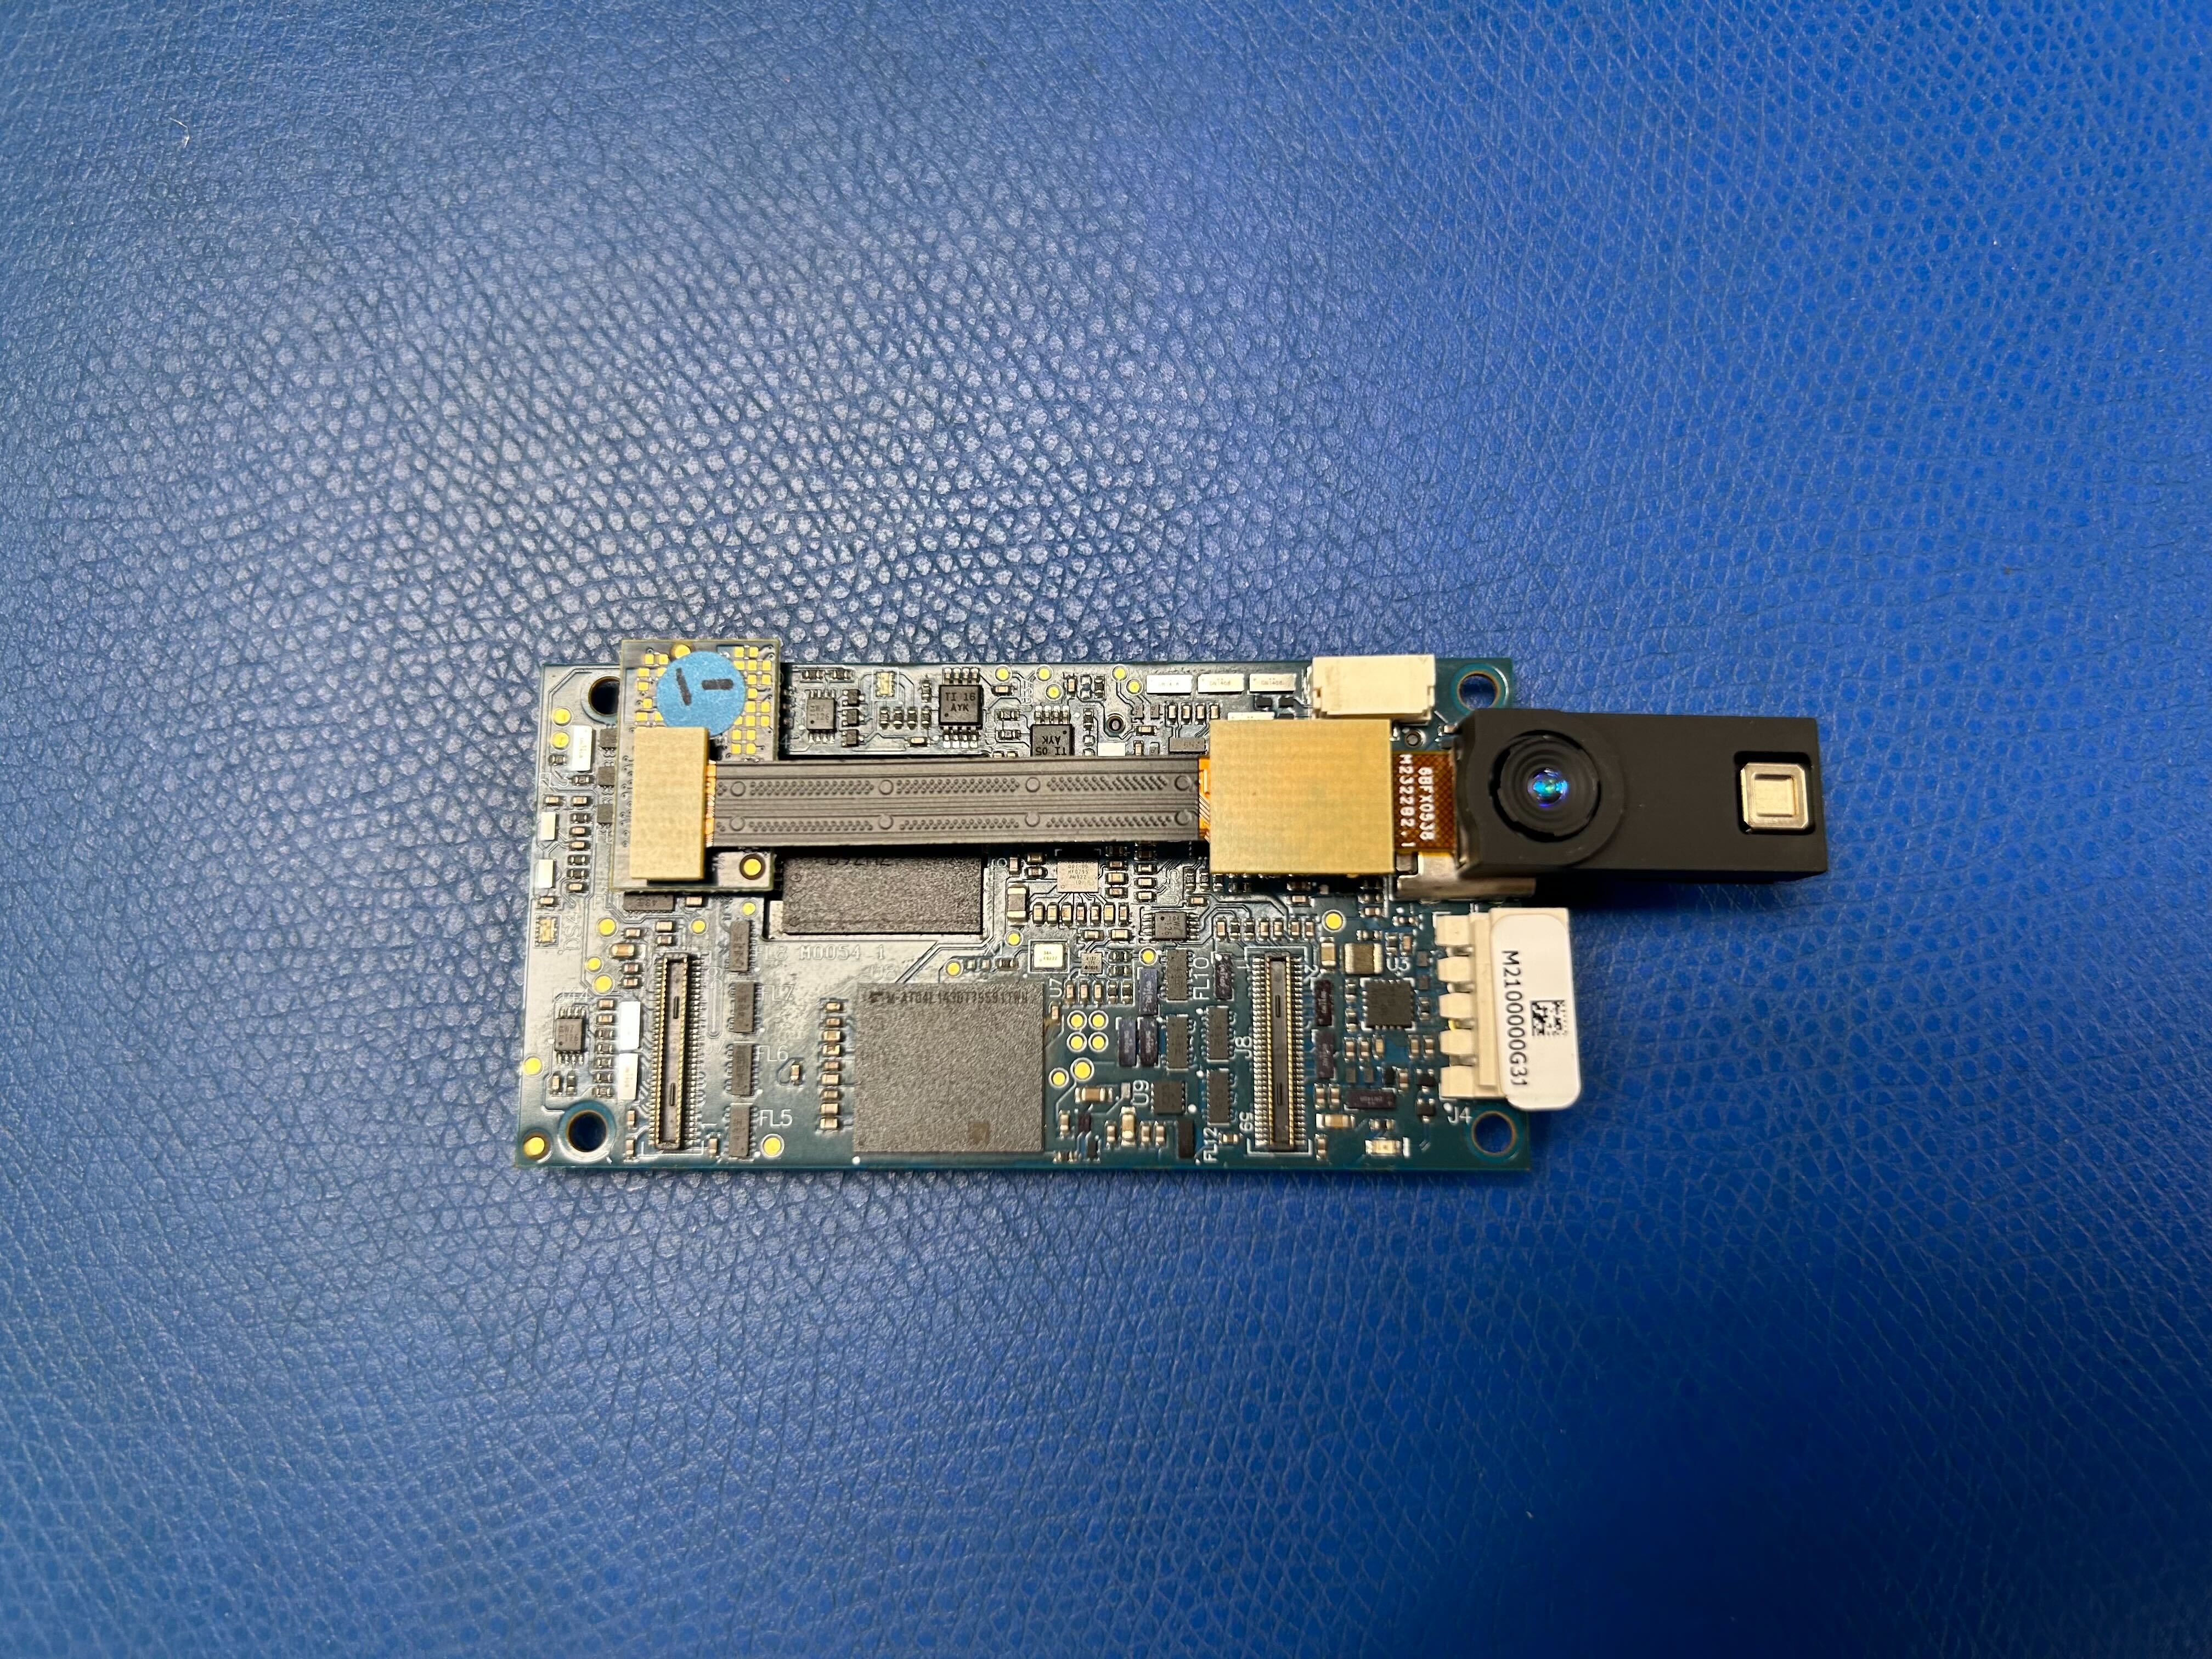
Config 10: OV7251 stereo only
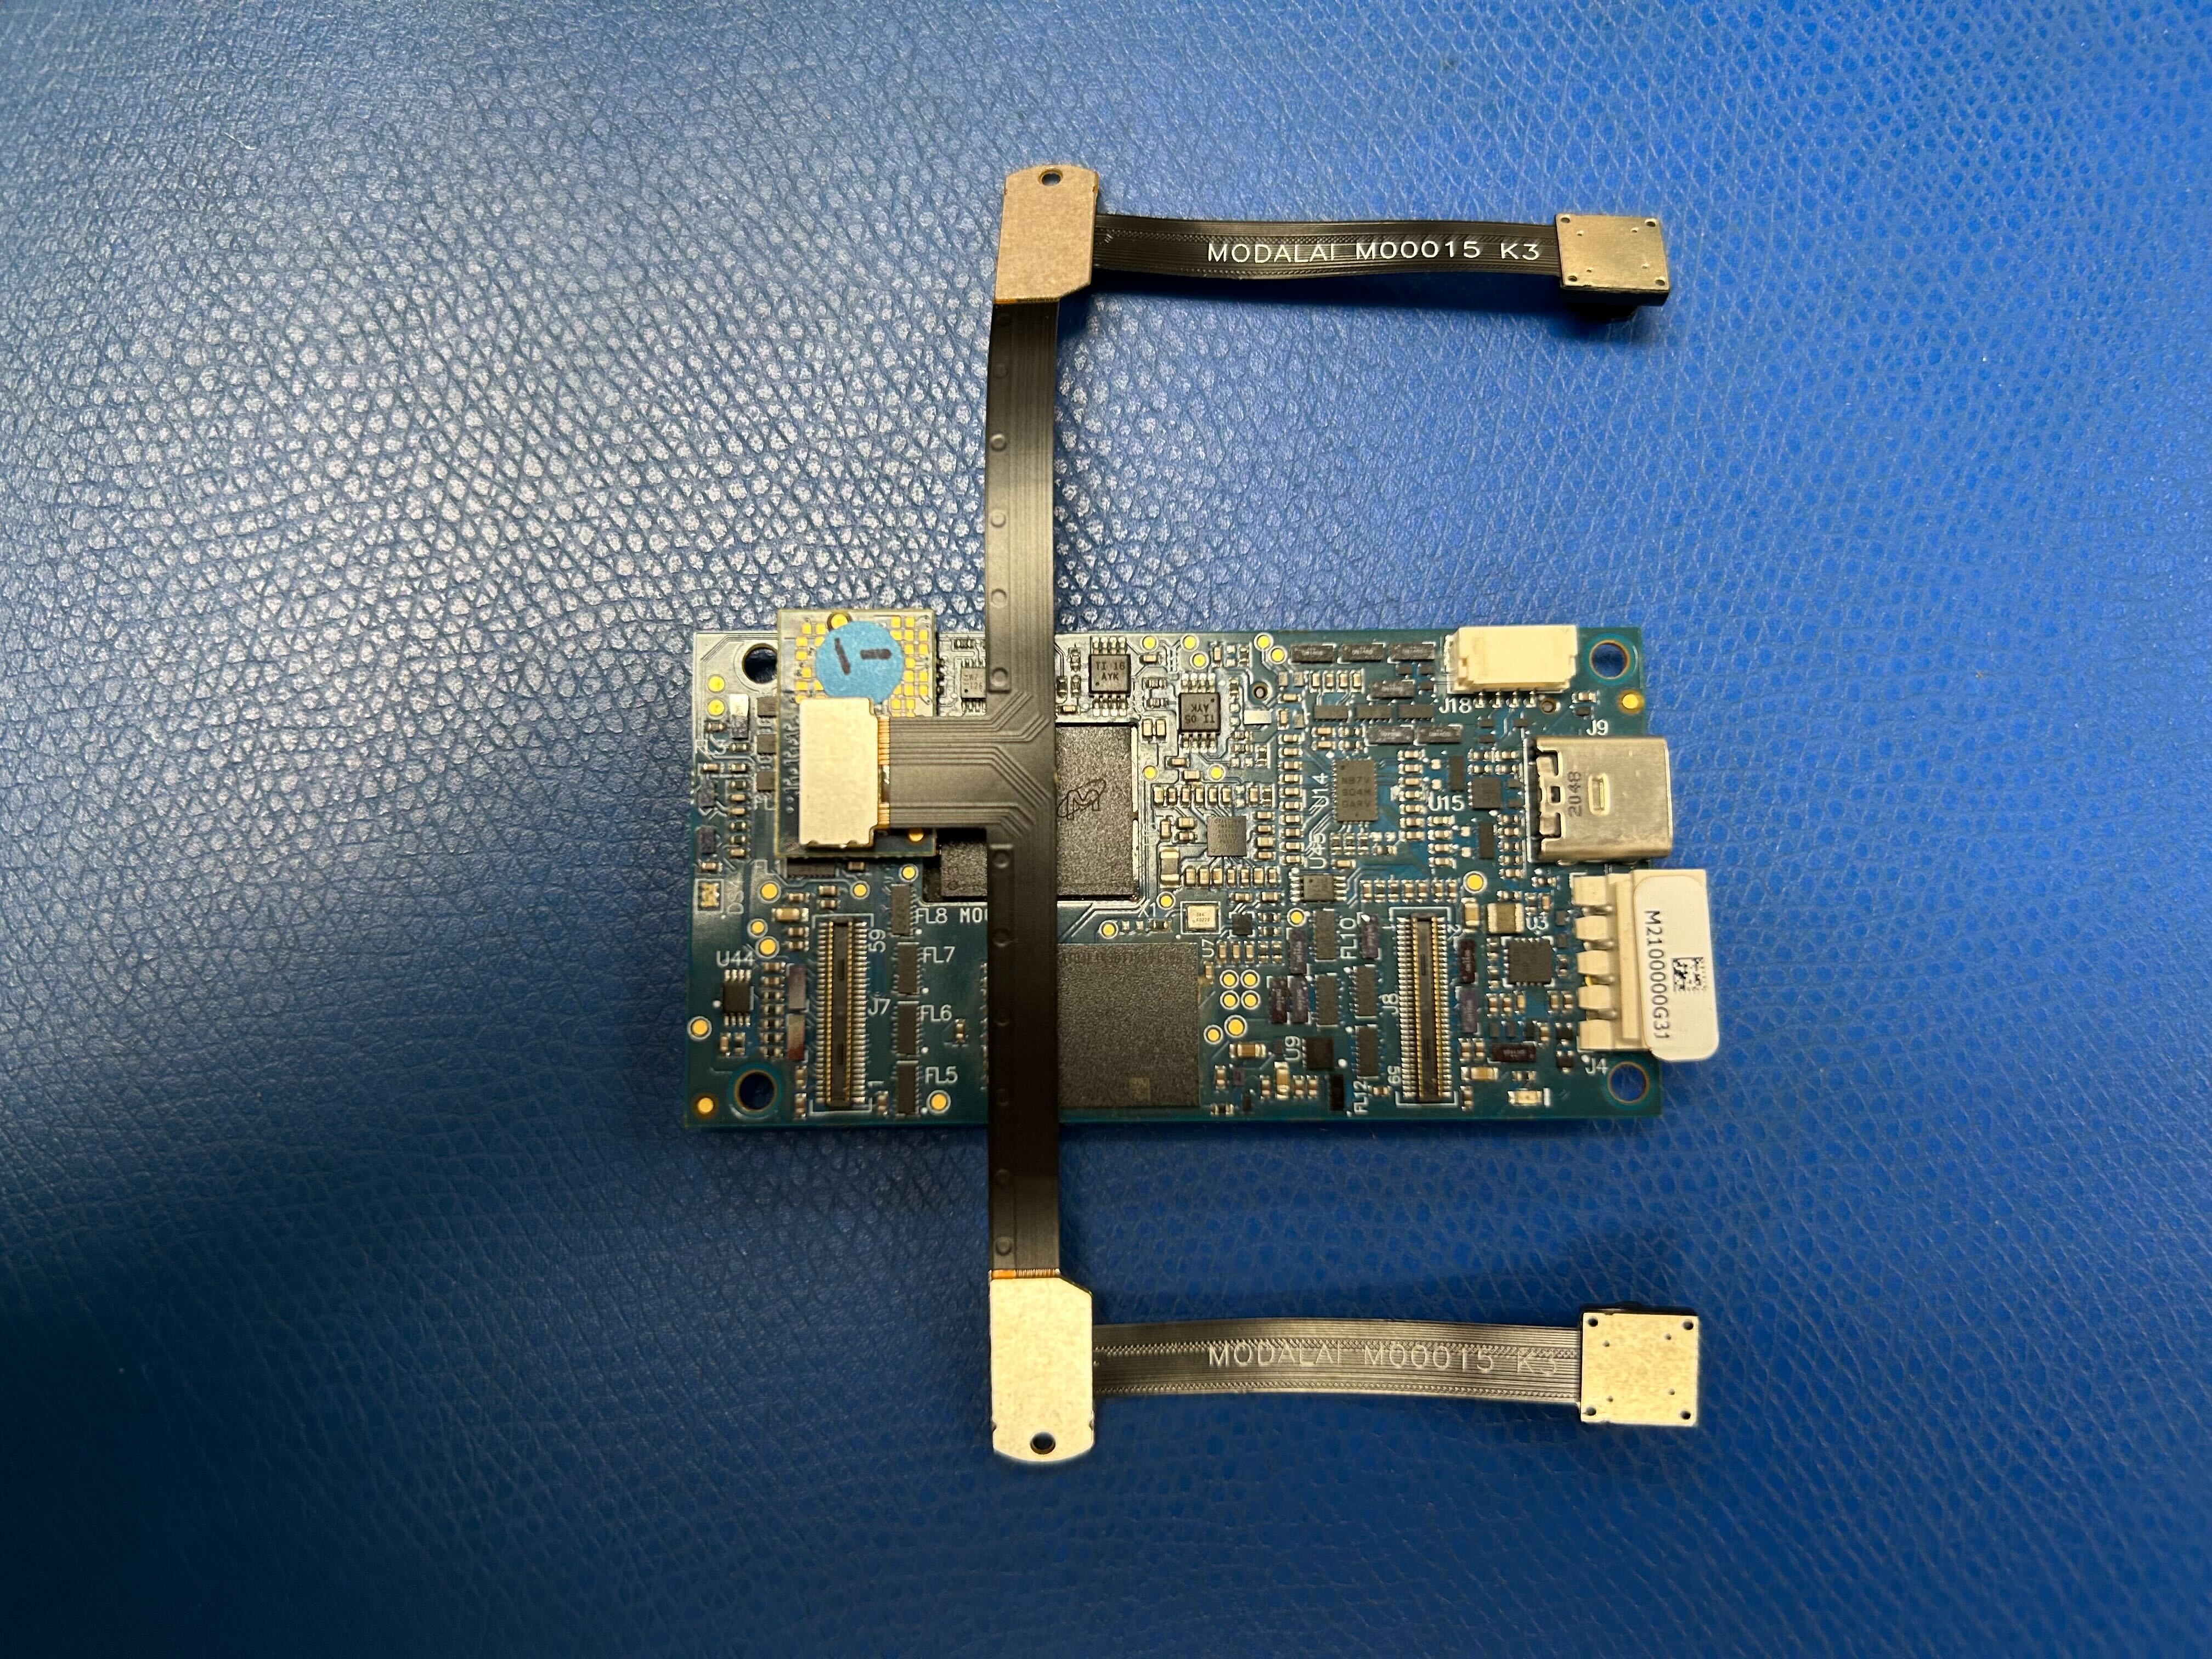
Config 11: D0006 Sentinel: front and rear OV7251 stereo, tracking, and IMX214 hires
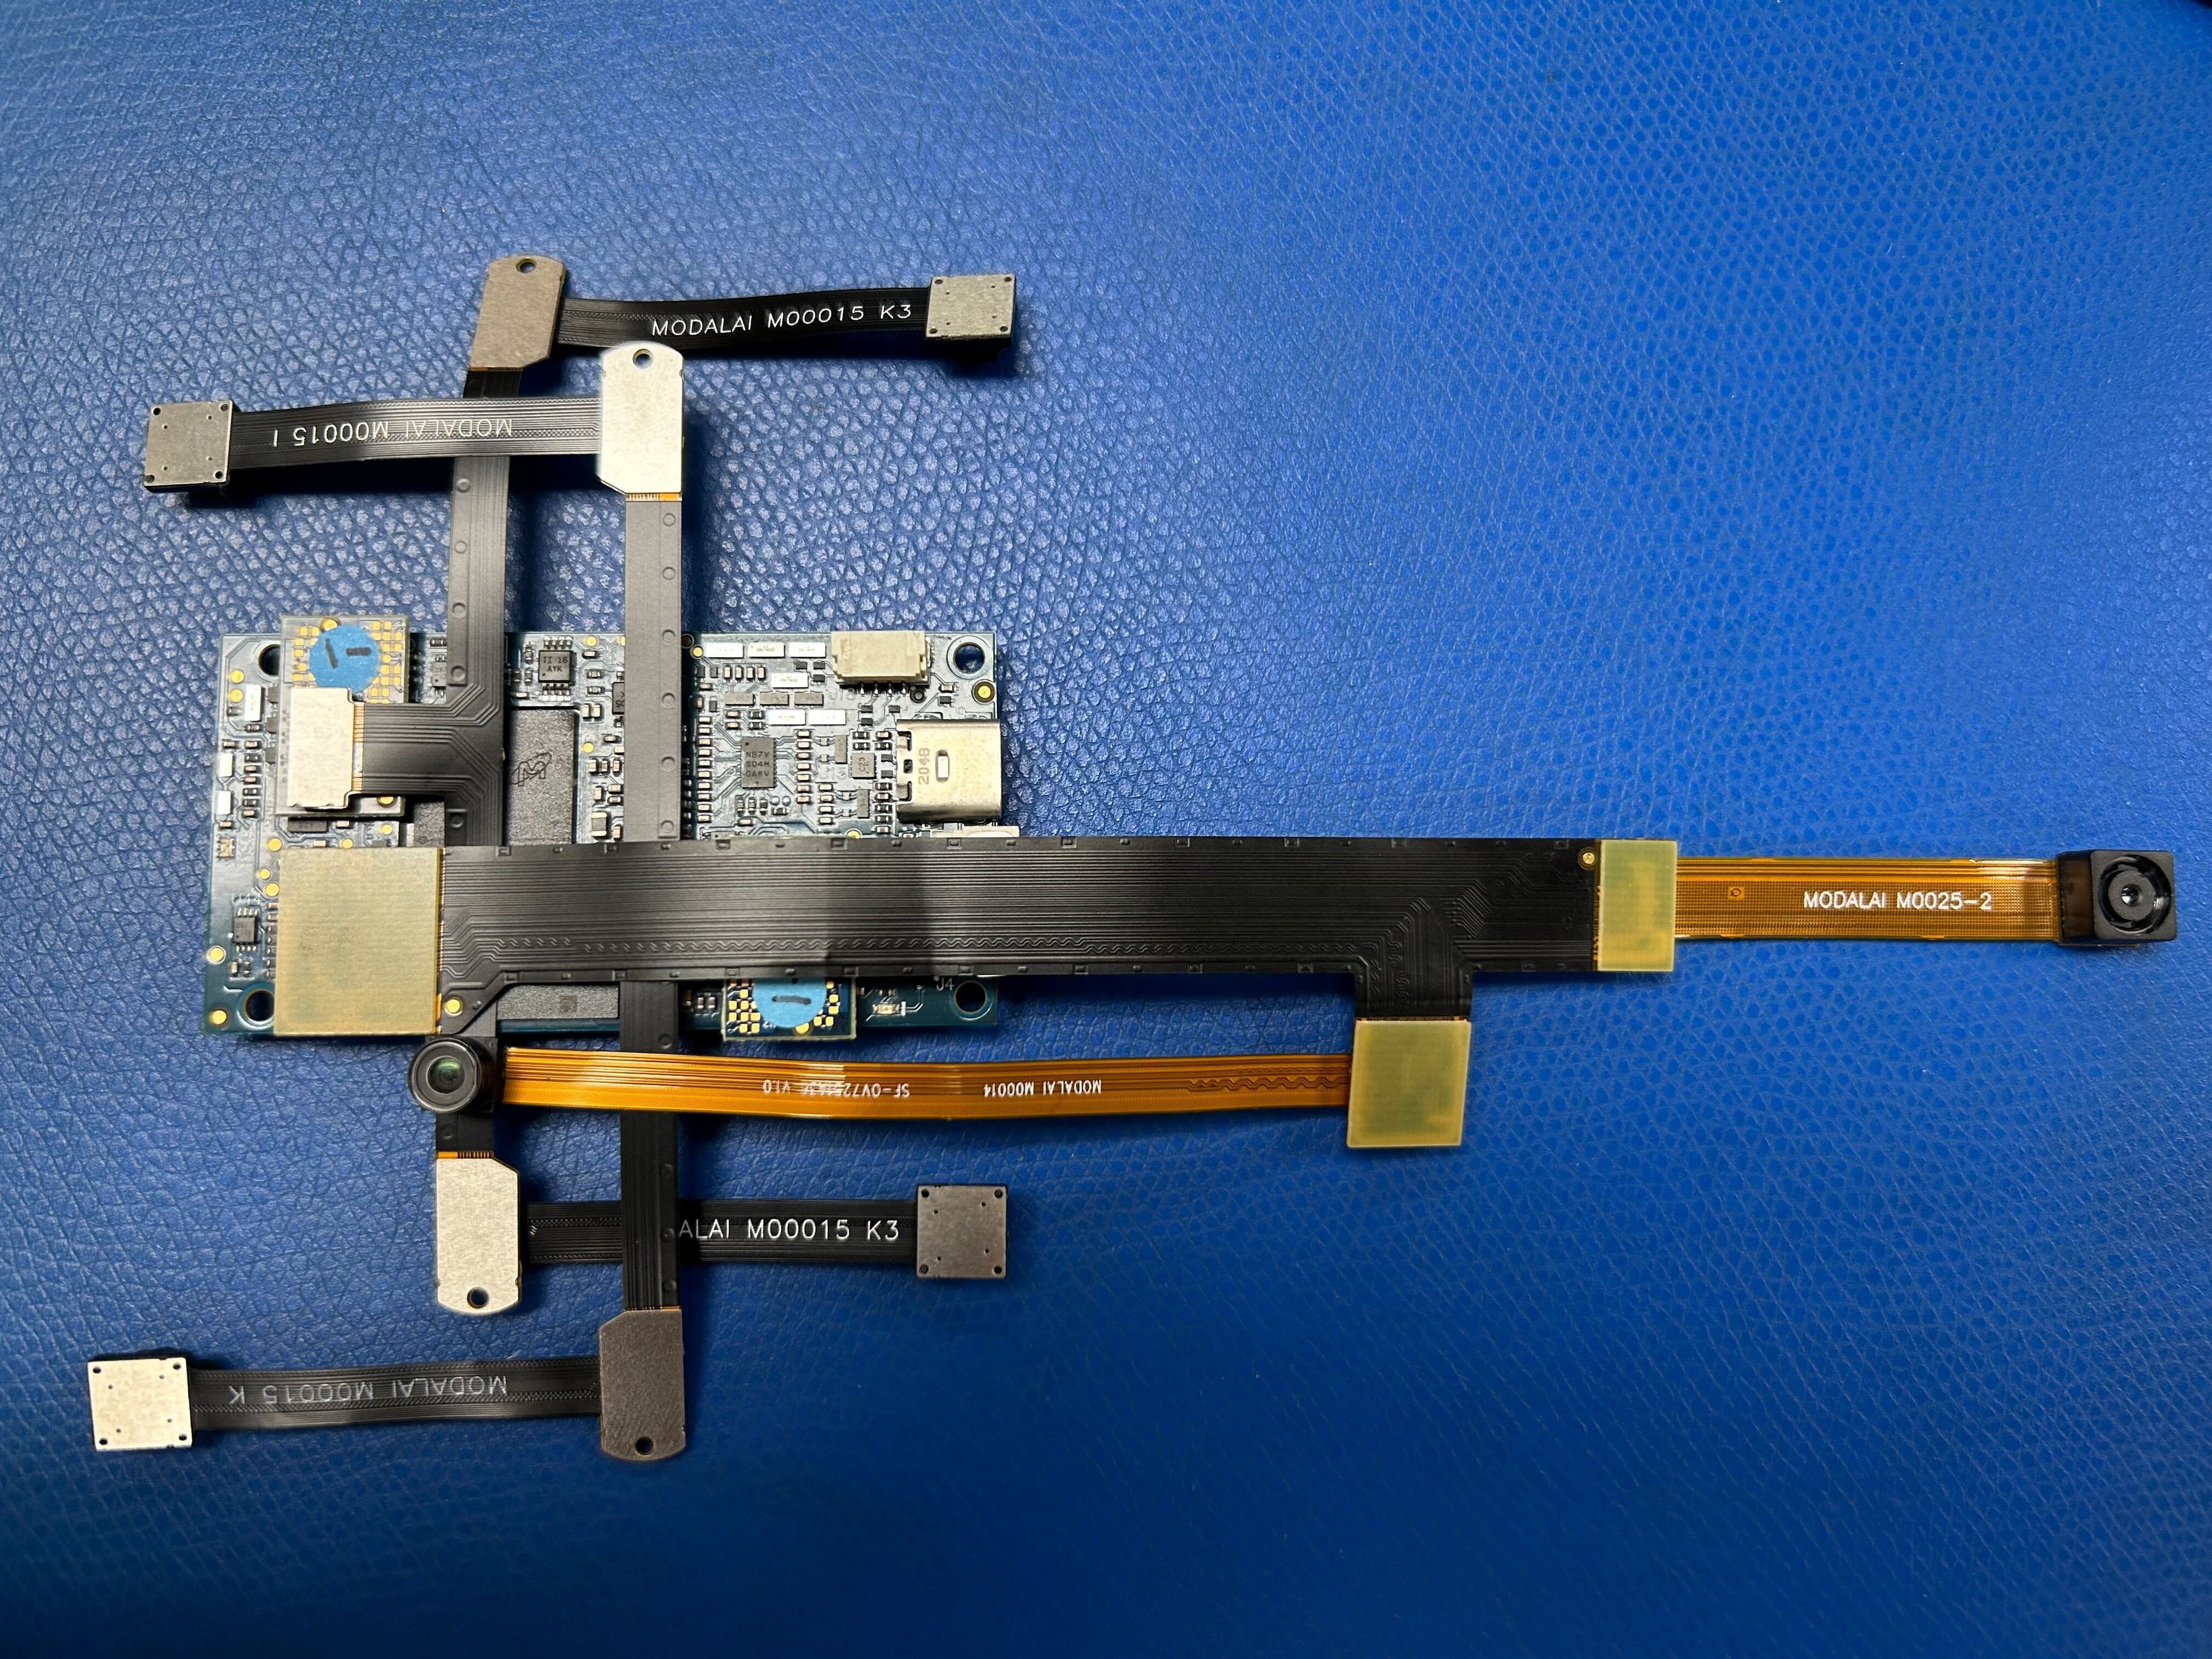
Config 12: OV9782 pair as two independent cameras
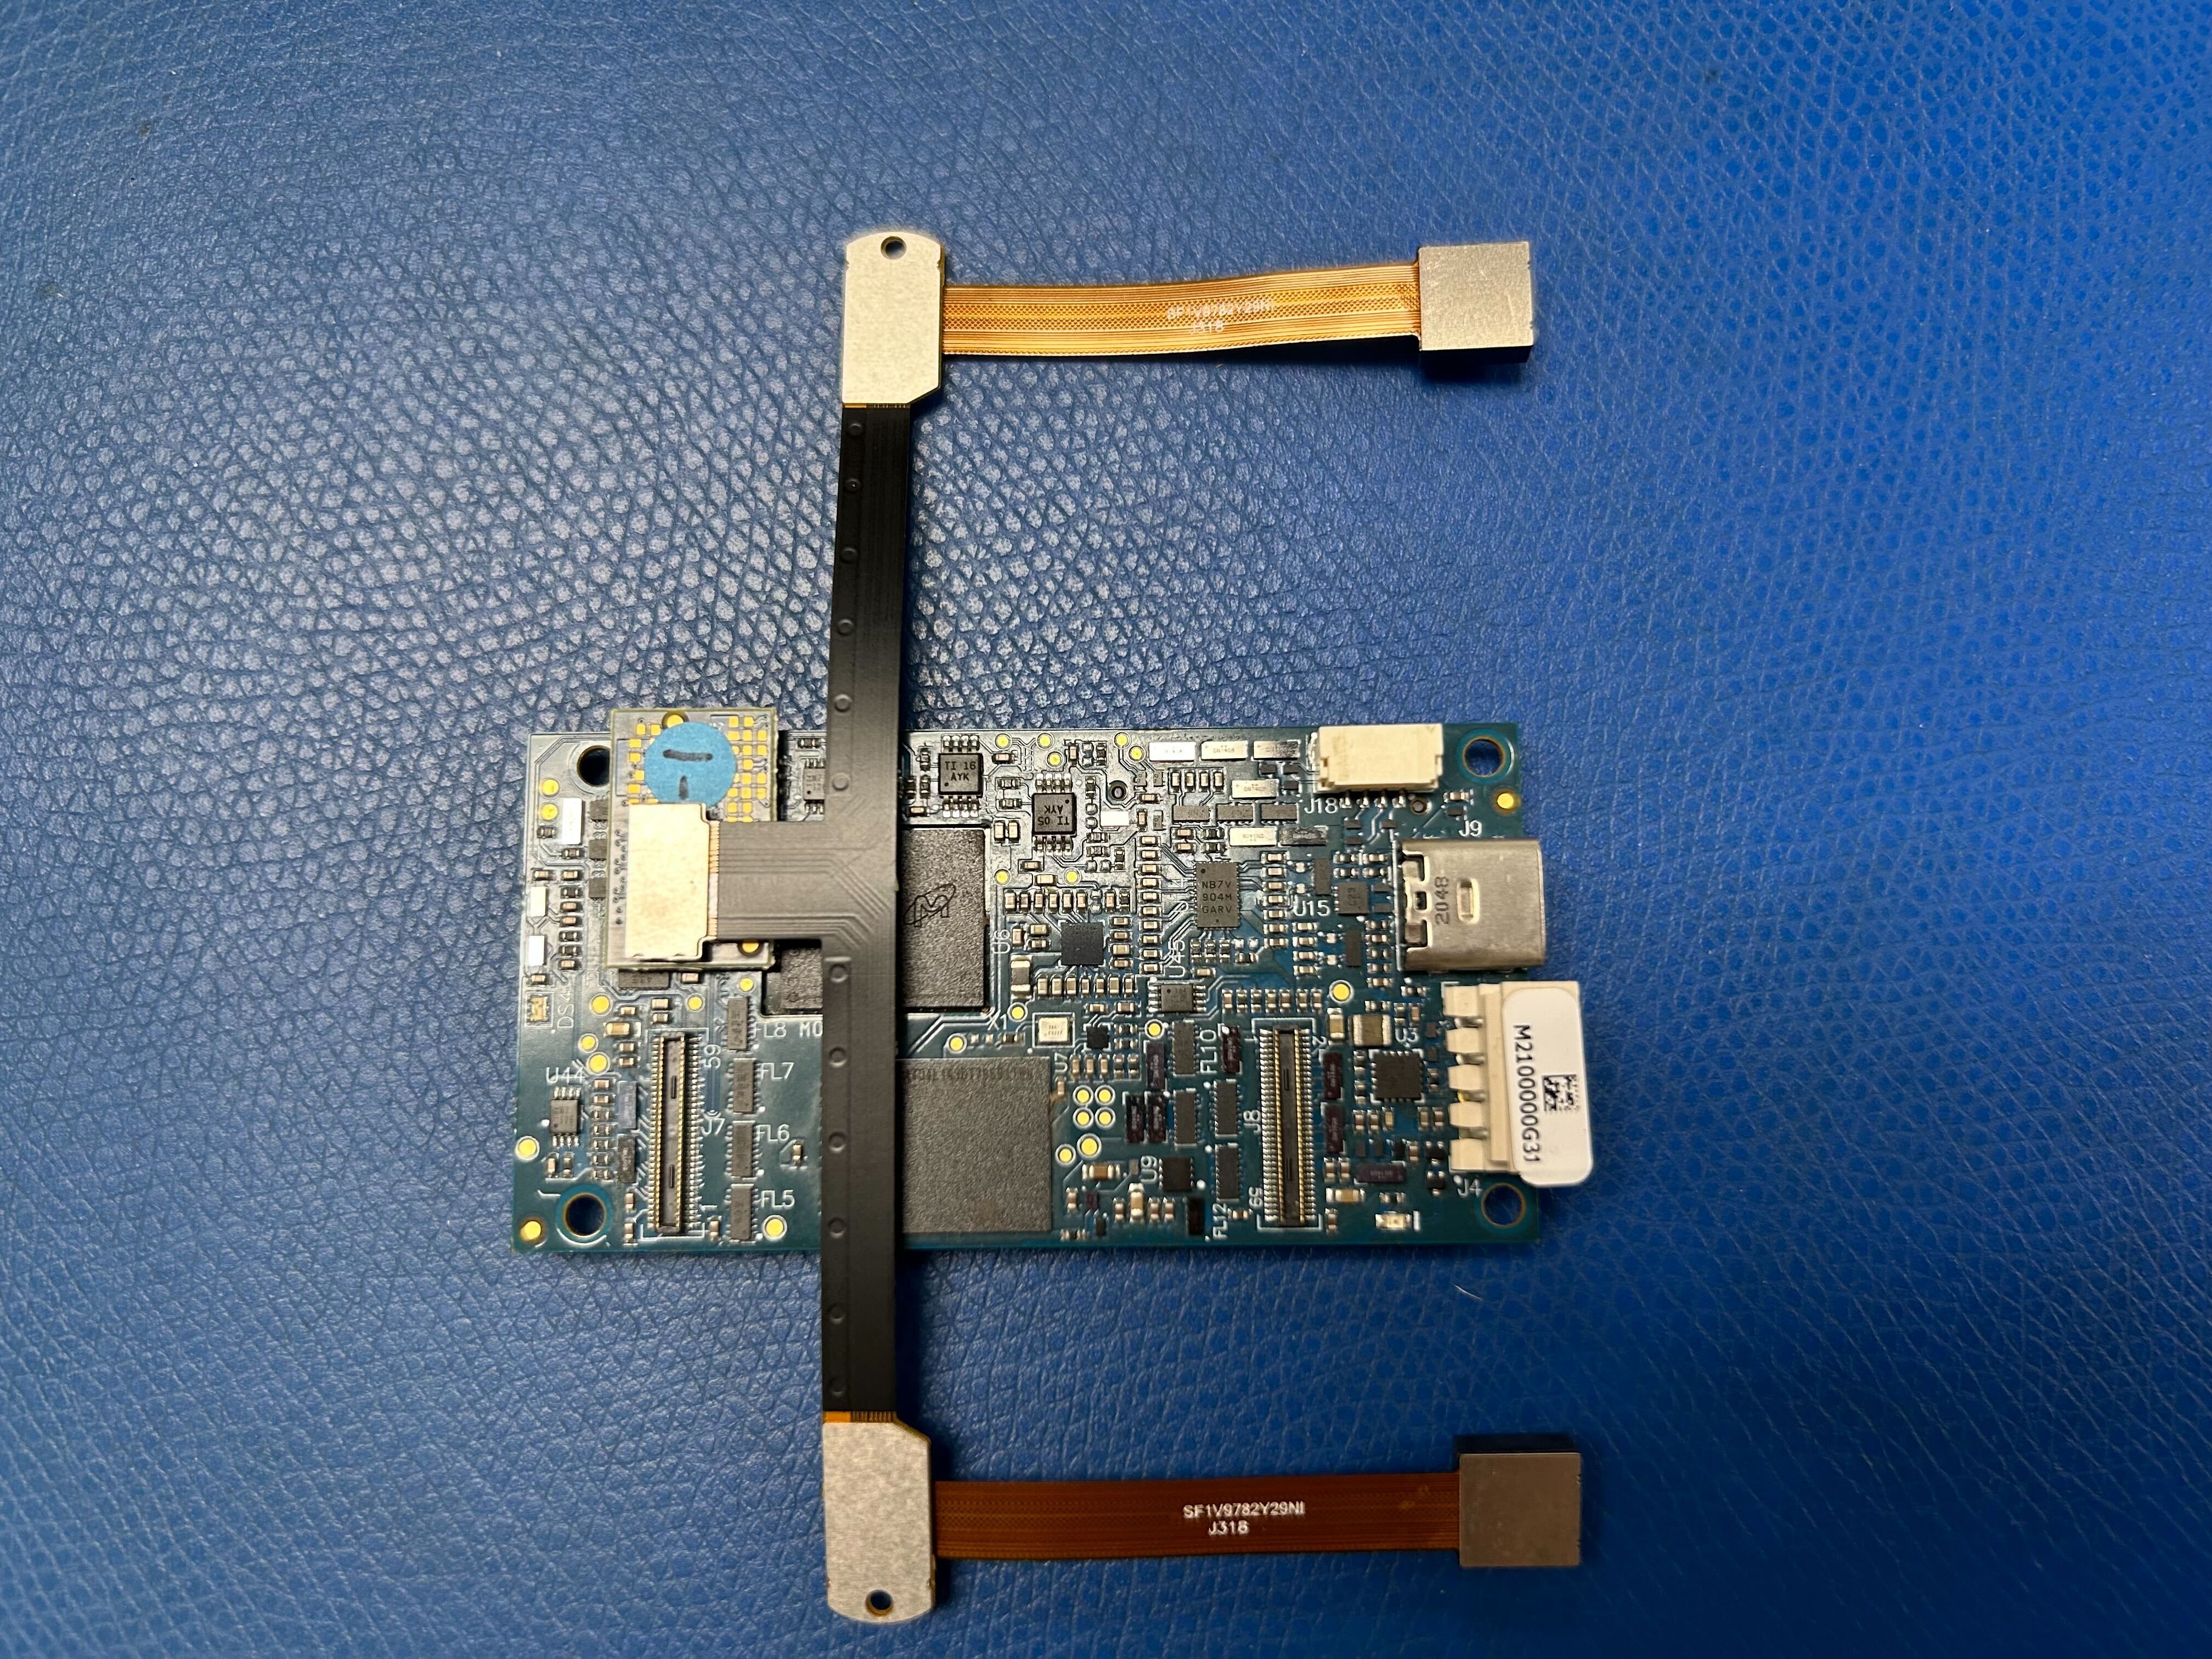
Config 15 uses the same wiring.
Config 13: OV9782 stereo and IMX214 hires
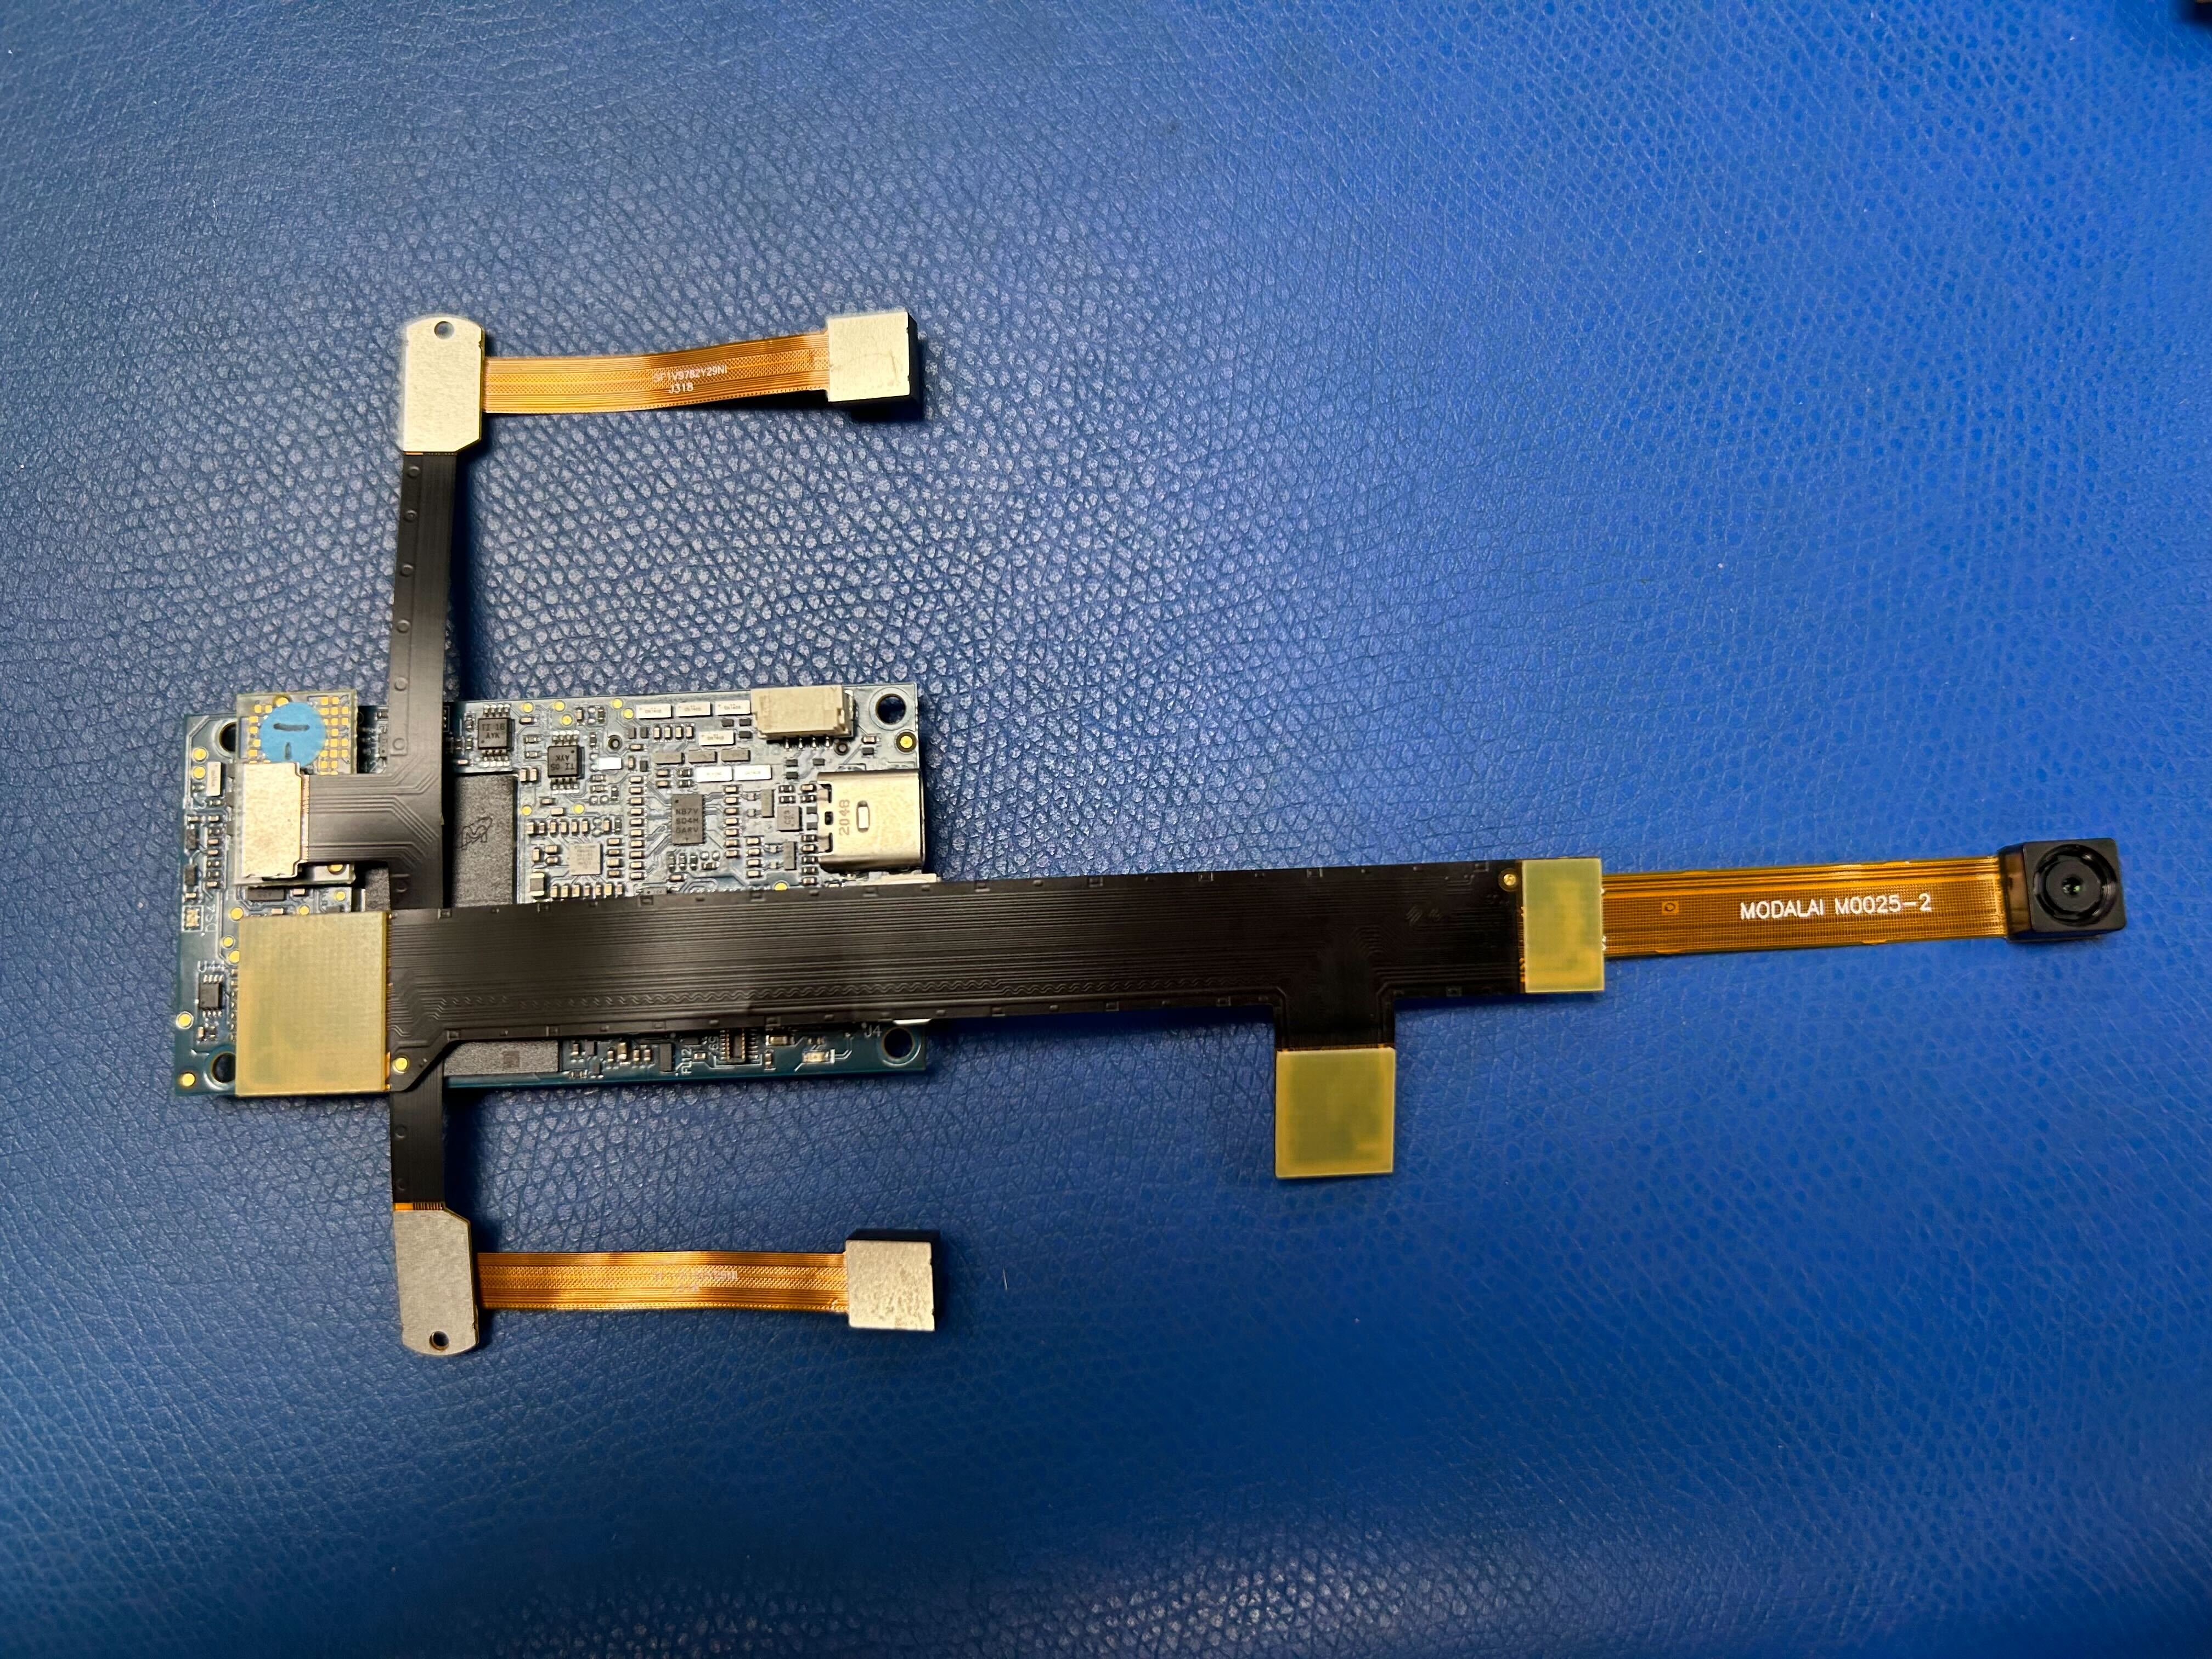
Config 16: ToF, IMX214 hires, and two OV7251 tracking

Config 17: D0010: ToF, IMX412 hires, OV7251 tracking, and OV9782 stereo

Limitations
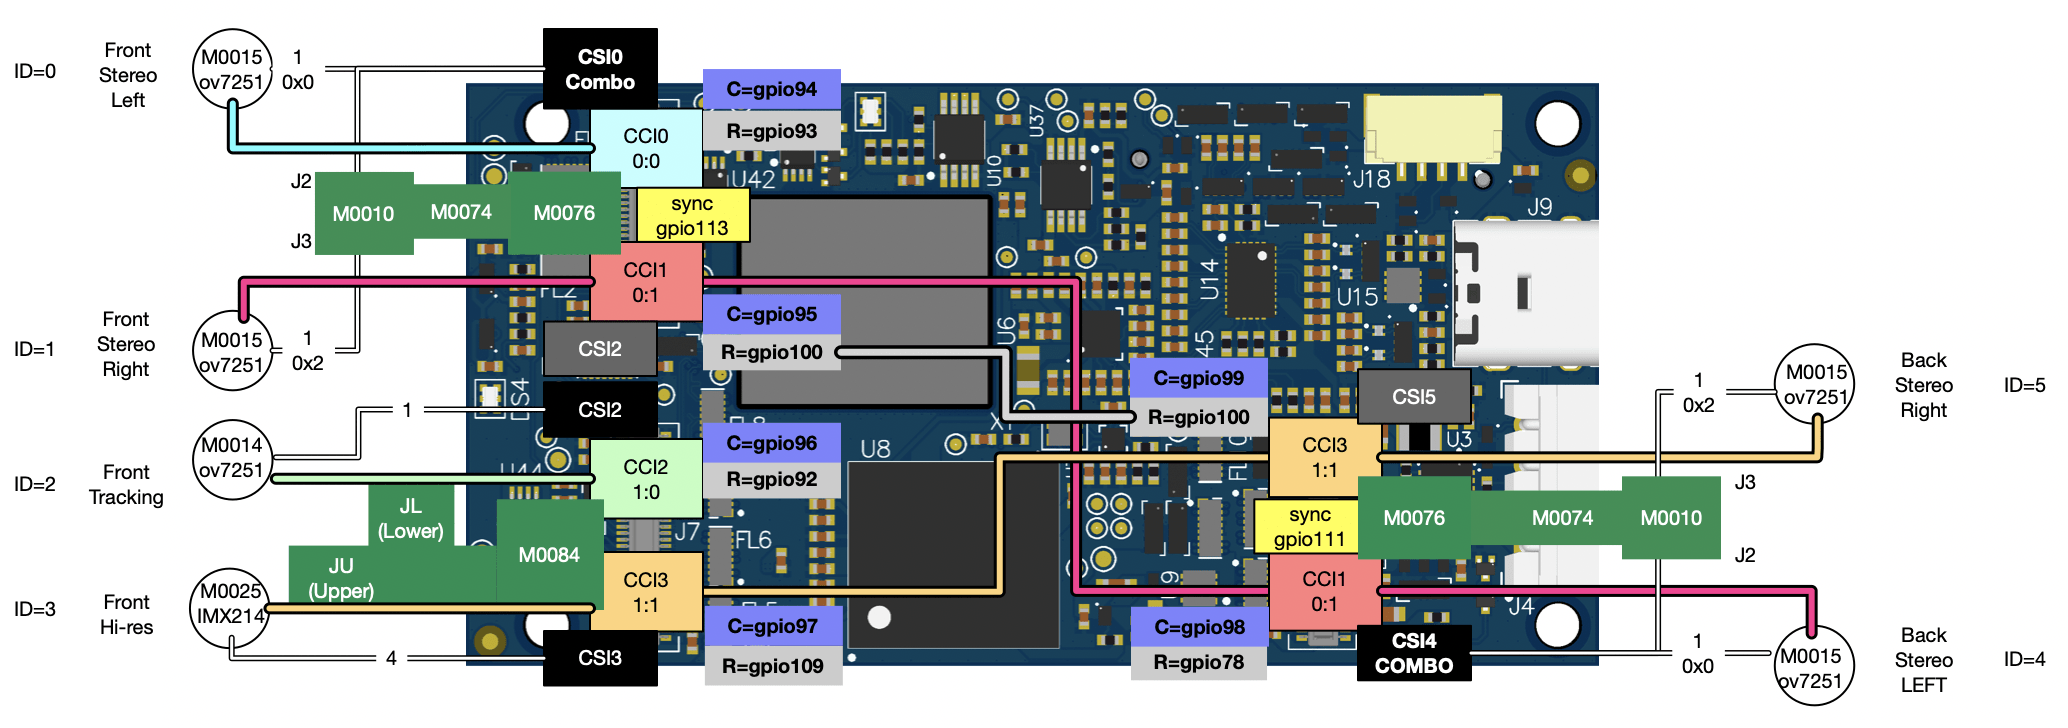
- To let several OV7251 sensors share
CCI3, the kernel skips sensor resets that Qualcomm’s driver would normally do, so the sensors keep their runtime address swap.dmesgshowsMODALAI HACKwhere this happens. - Slots 1 and 5 share a reset line (gpio100). No defects are known.
- All camera AVDD rails (2.8 V) stay on, since they are shared.
Legacy configurations (Platform Release 0.9.x)
These configurations apply to images before SDK 1.0 (Platform Release 0.9 and 0.9.5) and are kept for reference only.
Platform Release 0.9 and 0.9.5 sensor tables and wiring
Platform Release 0.9.5
- SDK 0.9.5
- System Image 1.5.5
Changes
- Added IMX678 support 1920x1080@30, 3840x2160@30
- Enabled more sensor options (see table below)
1.5.5 Supported Sensor Hardware IDs
| HW Sensor ID | Sensor Type | Description | Interposer |
|---|---|---|---|
| 0 | OV7251 M0015 | Stereo | M0010 + M0076 |
| 0 | OV9782 M0113 | Stereo | M0010 + M0076 |
| 0 | PMD TOF M0040 | ToF | M0040 + M0076 |
| HW Sensor ID | Sensor Type | Description | Interposer |
|---|---|---|---|
| 1 | OV7251 M0015 | Stereo | M0010 + M0076 |
| 1 | OV9782 M0113 | Stereo | M0010 + M0076 |
| 1 | PMD TOF M0040 | ToF | NA |
| HW Sensor ID | Sensor Type | Description | Interposer |
|---|---|---|---|
| 2 | OV7251 M0014 | Tracking | M0076, M0084 JL |
| 2 | ov9782 | Tracking | M0076, M0084 JL |
| 2 | PMD TOF M0040 | Depth | M0076, M0084 JL |
| 2 | IMX678 M0061-2 | Hi-res | M0076, M0084 JL |
| 2 | IMX412 M0107 | Hi-res | M0076, M0084 JL |
| 2 | IMX214 M0025-2 | Hi-res | M0076, M0084 JL |
| HW Sensor ID | Sensor Type | Description | Interposer |
|---|---|---|---|
| 3 | IMX678 M0061-2 | Hi-res | M0084 JU |
| 3 | IMX412 M0107 | Hi-res | M0084 JU |
| 3 | IMX214 M0025-2 | Hi-res | M0084 JU |
| 3 | PMD TOF M0040 | ToF | M0084 JU |
| HW Sensor ID | Sensor Type | Description | Interposer |
|---|---|---|---|
| 4 | OV7251 M0015 | Stereo | M0010 + M0076 |
| 4 | OV9782 M0113 | Stereo | M0010 + M0076 |
| 4 | PMD TOF M0040 | ToF | M0040 + M0076 |
| 4 | IMX678 M0061-2 | Hi-res | M0076, M0084 JL |
| 4 | IMX412 M0107 | Hi-res | M0076, M0084 JL |
| 4 | IMX214 M0025-2 | Hi-res | M0076, M0084 JL |
| HW Sensor ID | Sensor Type | Description | Interposer |
|---|---|---|---|
| 5 | OV7251 M0015 | Stereo | M0010 + M0076 |
| 5 | OV9782 M0113 | Stereo | M0010 + M0076 |
| 5 | PMD TOF M0040 | ToF | NA |
| 5 | IMX678 M0061-2 | Hi-res(alt address 0x20) | M0076, M0084 JL |
1.5.5 Supported Sensor Settings
Some sensors may list additional capabilities when probed from software. Below are what we’ve tested against, other settings may have unexpected results.
| Sensor | Sensor Type | Resolution @ FPS |
|---|---|---|
| IMX678 M0061-2 | Hi-res | 3840x2160 @ 30 1920x1080 @ 30 |
| IMX412/577 M0107 | Hi-res | 1920x1080 @ 30 |
| IMX214 M0025-2 | Hi-res | 4096 x 2160 @ 30 3840x2160 @ 30 2048x1536 @ 30 1920 x 1080 @ 30 1280 x 720 @ 30 1024 x 768 @ 30 640 x 480 @ 30 |
| PMD TOF M0040 | ToF | 224 x 1557 @ 5 |
| OV7251 M0014 | Tracking Config | 640x480 @ 30 |
| OV7251 M0015 | Stereo Config Left | 640x480 @ 30 |
| OV7251 M0015 | Stereo Config Right | 640x480 @ 30 |
| ov9782 | Tracking Config | 1280x800 @ 30 |
| OV9782 M0113 | Stereo Config Left | 1280x800 @ 30 |
| OV9782 M0113 | Stereo Config Right | 1280x800 @ 30 |
Platform Release 0.9
- SDK 0.9
- System Image 1.4.1
1.4.1 Supported Sensor Hardware IDs
1.4.1 Supported Sensor Settings
| Sensor | Sensor Type | Resolution @ FPS |
|---|---|---|
| IMX214 M0025-2 | Hi-res | 4096 x 2160 @ 30 3840x2160 @ 30 2048x1536 @ 30 1920 x 1080 @ 30 1280 x 720 @ 30 1024 x 768 @ 30 640 x 480 @ 30 |
| IMX412/577 M0107 | Hi-resConfig | 1920x1080 @ 30 |
| PMD TOF M0040 | ToF | 224 x 1557 @ 5 |
| OV7251 M0014 | Tracking Config | 640x480 @ 30 |
| OV7251 M0015 | Stereo Config Left | 640x480 @ 30 |
| OV7251 M0015 | Stereo Config Right | 640x480 @ 30 |
| ov9782 | Tracking Config | 1280x800 @ 30 |
| OV9782 M0113 | Stereo Config Left | 1280x800 @ 30 |
| OV9782 M0113 | Stereo Config Right | 1280x800 @ 30 |
Image Sensor Configurations - SDK 0.9.5
C3 - Front Stereo, Hires, and Tracking

| Sensor ID | Sensor Type | Notes | Usage |
|---|---|---|---|
| 0 (J6L) | OV7251 M0015 | Fsync in0 | Front stereo |
| 1 (J6L) | OV7251 M0015 | Fsync out0 | Front stereo |
| 2 (J7L) | ov7251 | Tracking | |
| 3 (J7U) | imx214, imx412 | Hi-res |
C4 - Tracking and Hires Only

| Sensor ID | Sensor Type | Notes | Usage |
|---|---|---|---|
| 2 (J7L) | ov7251 | Tracking | |
| 3 (J7U) | imx214, imx412 | Hi-res |
C6 - Hires + ToF + Tracking
Available starting with Platform Release 0.9, sys img 1.4.1.
HW Setup
| Sensor ID | Sensor Type | Notes | Usage |
|---|---|---|---|
| 0 (J6L) | PMD TOF M0040 | Depth 0 | |
| 2 (J7L) | imx214, imx412 | Hi-res | |
| 3 (J7U) | ov7251 | Tracking |
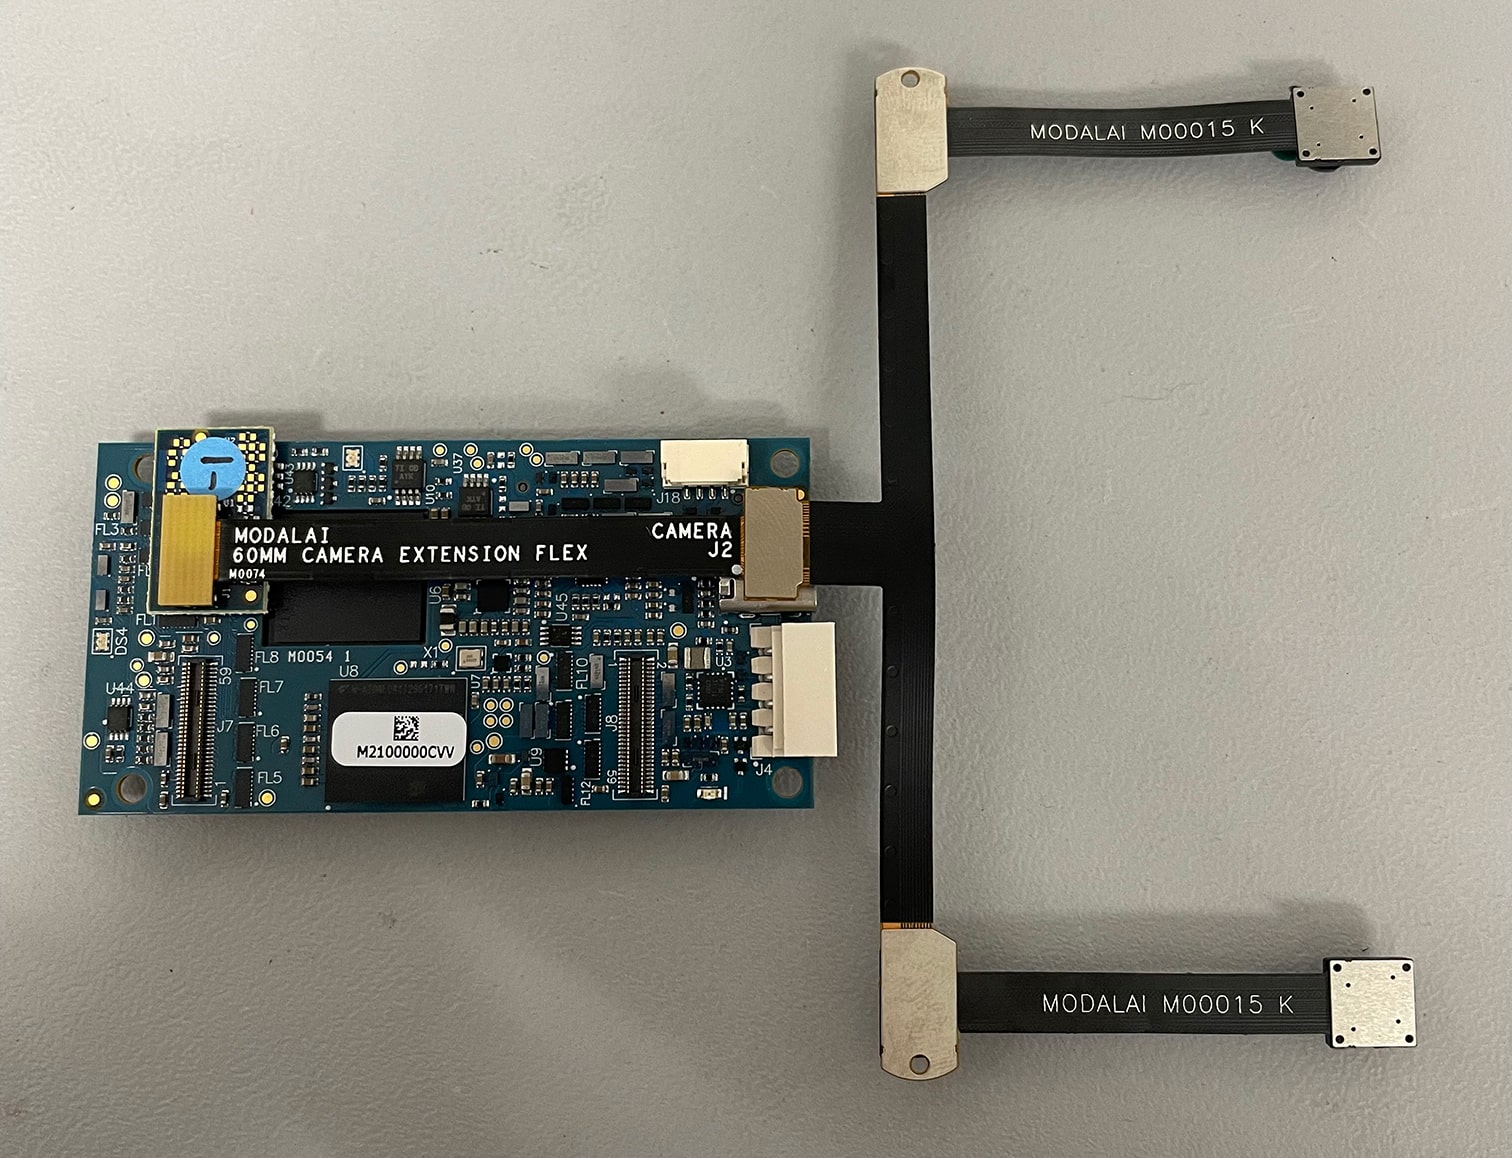
C10 - Front Stereo Only
| Sensor ID | Sensor Type | Notes | Usage |
|---|---|---|---|
| 0 (J6L) | OV7251 M0015 | Fsync in0 | Front stereo |
| 1 (J6L) | OV7251 M0015 | Fsync out0 | Front stereo |
C11 - Front Stereo, Rear Stereo, Hires, and Tracking

| Sensor ID | Sensor Type | Notes | Usage |
|---|---|---|---|
| 0 (J6L) | OV7251 M0015 | Fsync in0 | Front stereo |
| 1 (J6L) | OV7251 M0015 | Fsync out0 | Front stereo |
| 2 (J7L) | ov7251 | Tracking | |
| 3 (J7U) | imx214, imx412 | Hi-res | |
| 4 (J8L) | OV7251 M0015 | Fsync in1 | Rear stereo |
| 5 (J8L) | OV7251 M0015 | Fsync out1 | Rear stereo |
C8 - Hires Only
Available starting with Platform Release 0.9.5, sys img 1.5.3.
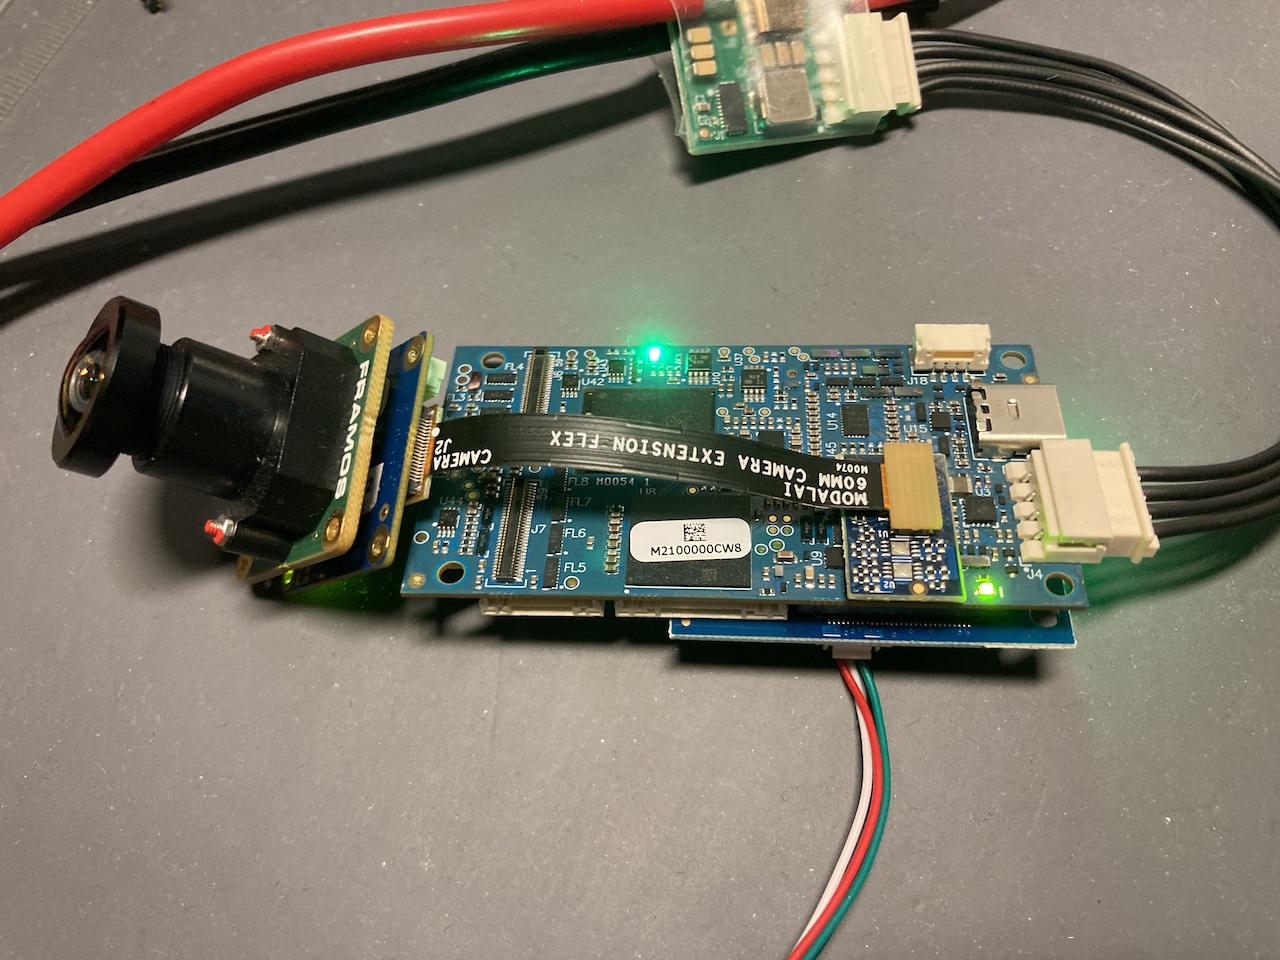
M0061-2 based IMX678, on M0054 J8 (no other camera location for IMX678 is supported in 1.5.3, must be J8).
Shown here, the M0076 interposer plugs into M0054 J8. The M0074 flex then connects to the M0061-2 backpack for the IMX678 module.
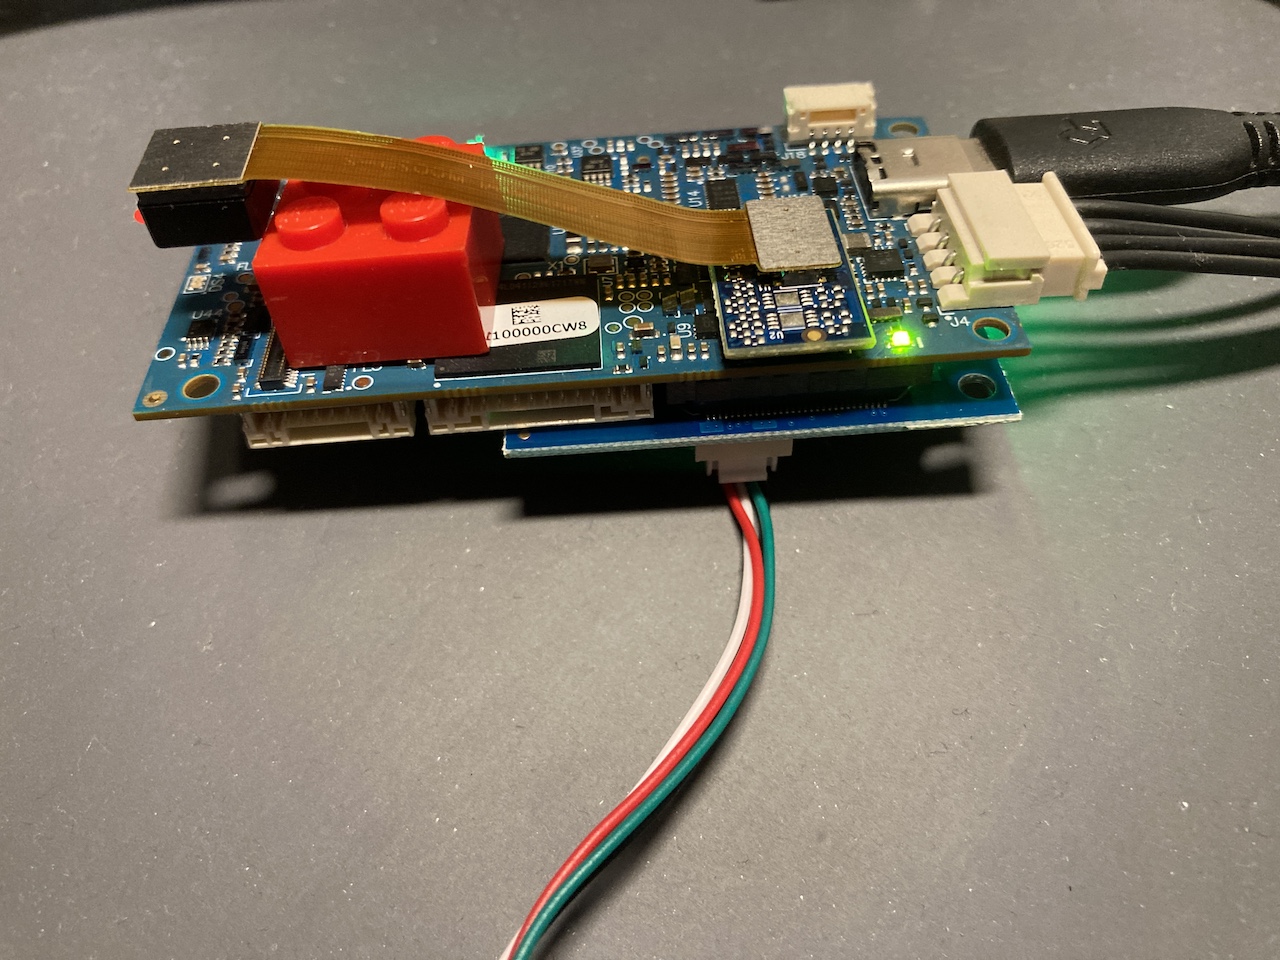
M0025-2 based IMX214, on M0054 J8.
SW Setup
voxl2:/$ voxl-configure-cameras 8
C9 - Time of Flight (ToF) Only
Available starting with Platform Release 0.9, sys img 1.4.1.
HW Setup
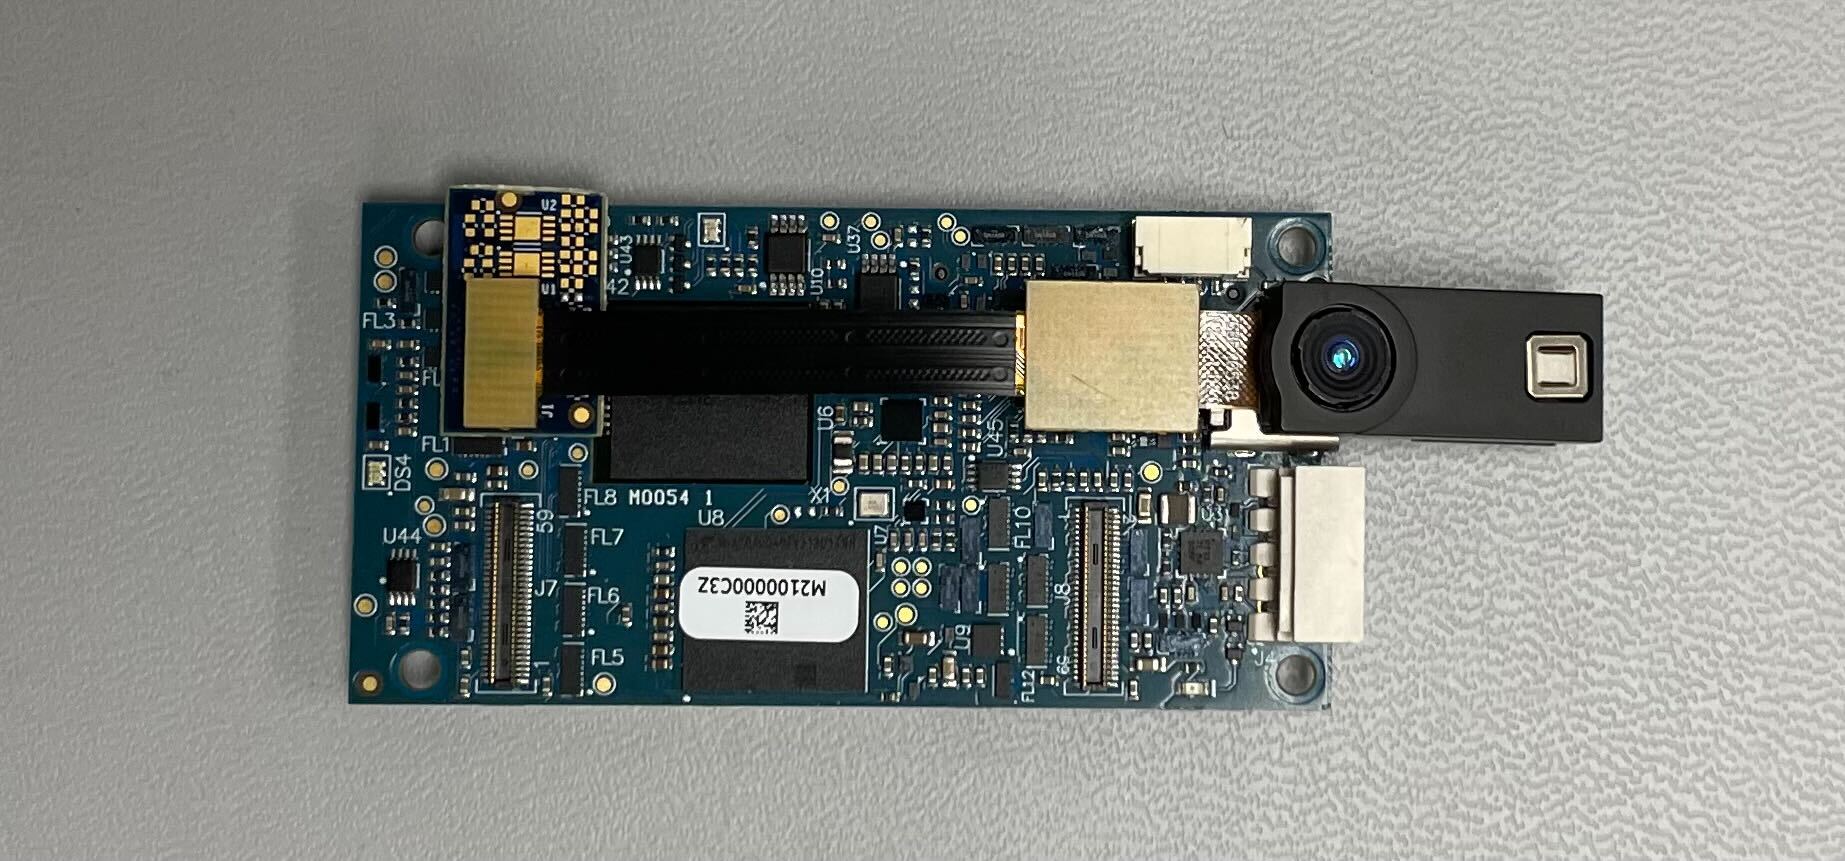
| Sensor ID | Sensor Type | Notes | Usage |
|---|---|---|---|
| 0 | PMD TOF M0040 | Depth 0 |
SW Setup
voxl2:/$ voxl-configure-cameras 9
CX - Two Time of Flights (ToF)
Available starting with Platform Release 0.9, sys img 1.4.1.
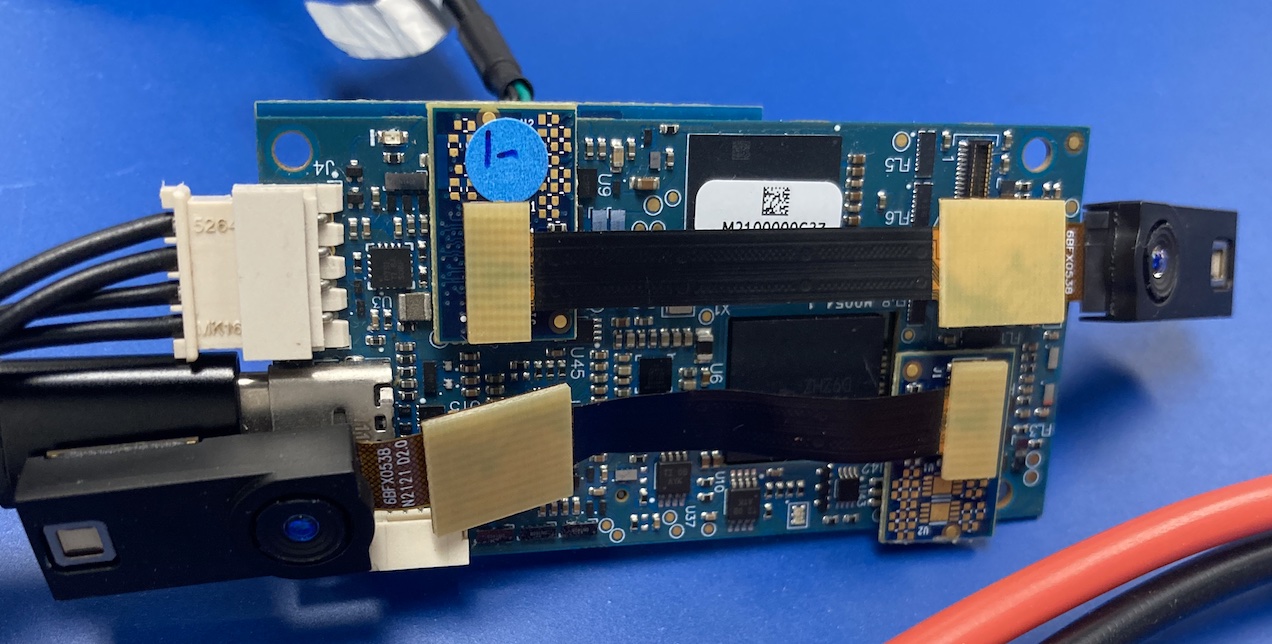
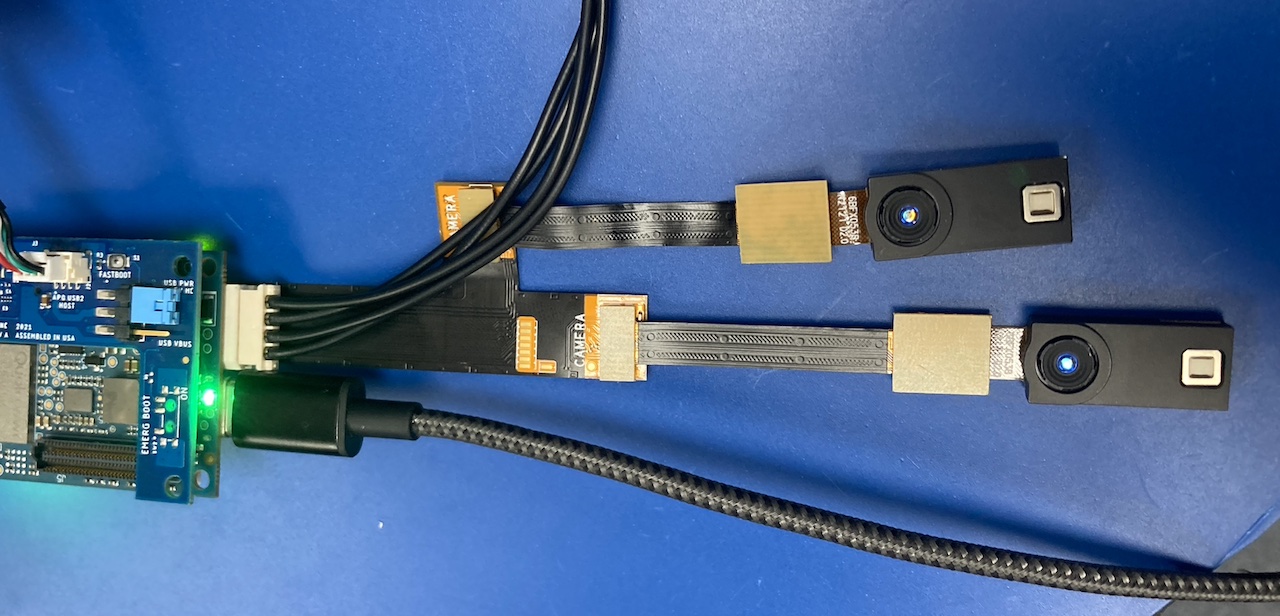
HW Setup
Using the M0076-1 interposers on J6 and J8 as examples:
Using the M0084-1 dual camera adapter (“y-flex”) on J8 as example:
SW Setup
NA